Developing a cheap DIY alternative to expensive machined ballscrew actuators (with a little less precision). For humanoid robots.
To make the experience fit your profile, pick a username and tell us what interests you.
We found and based on your interests.
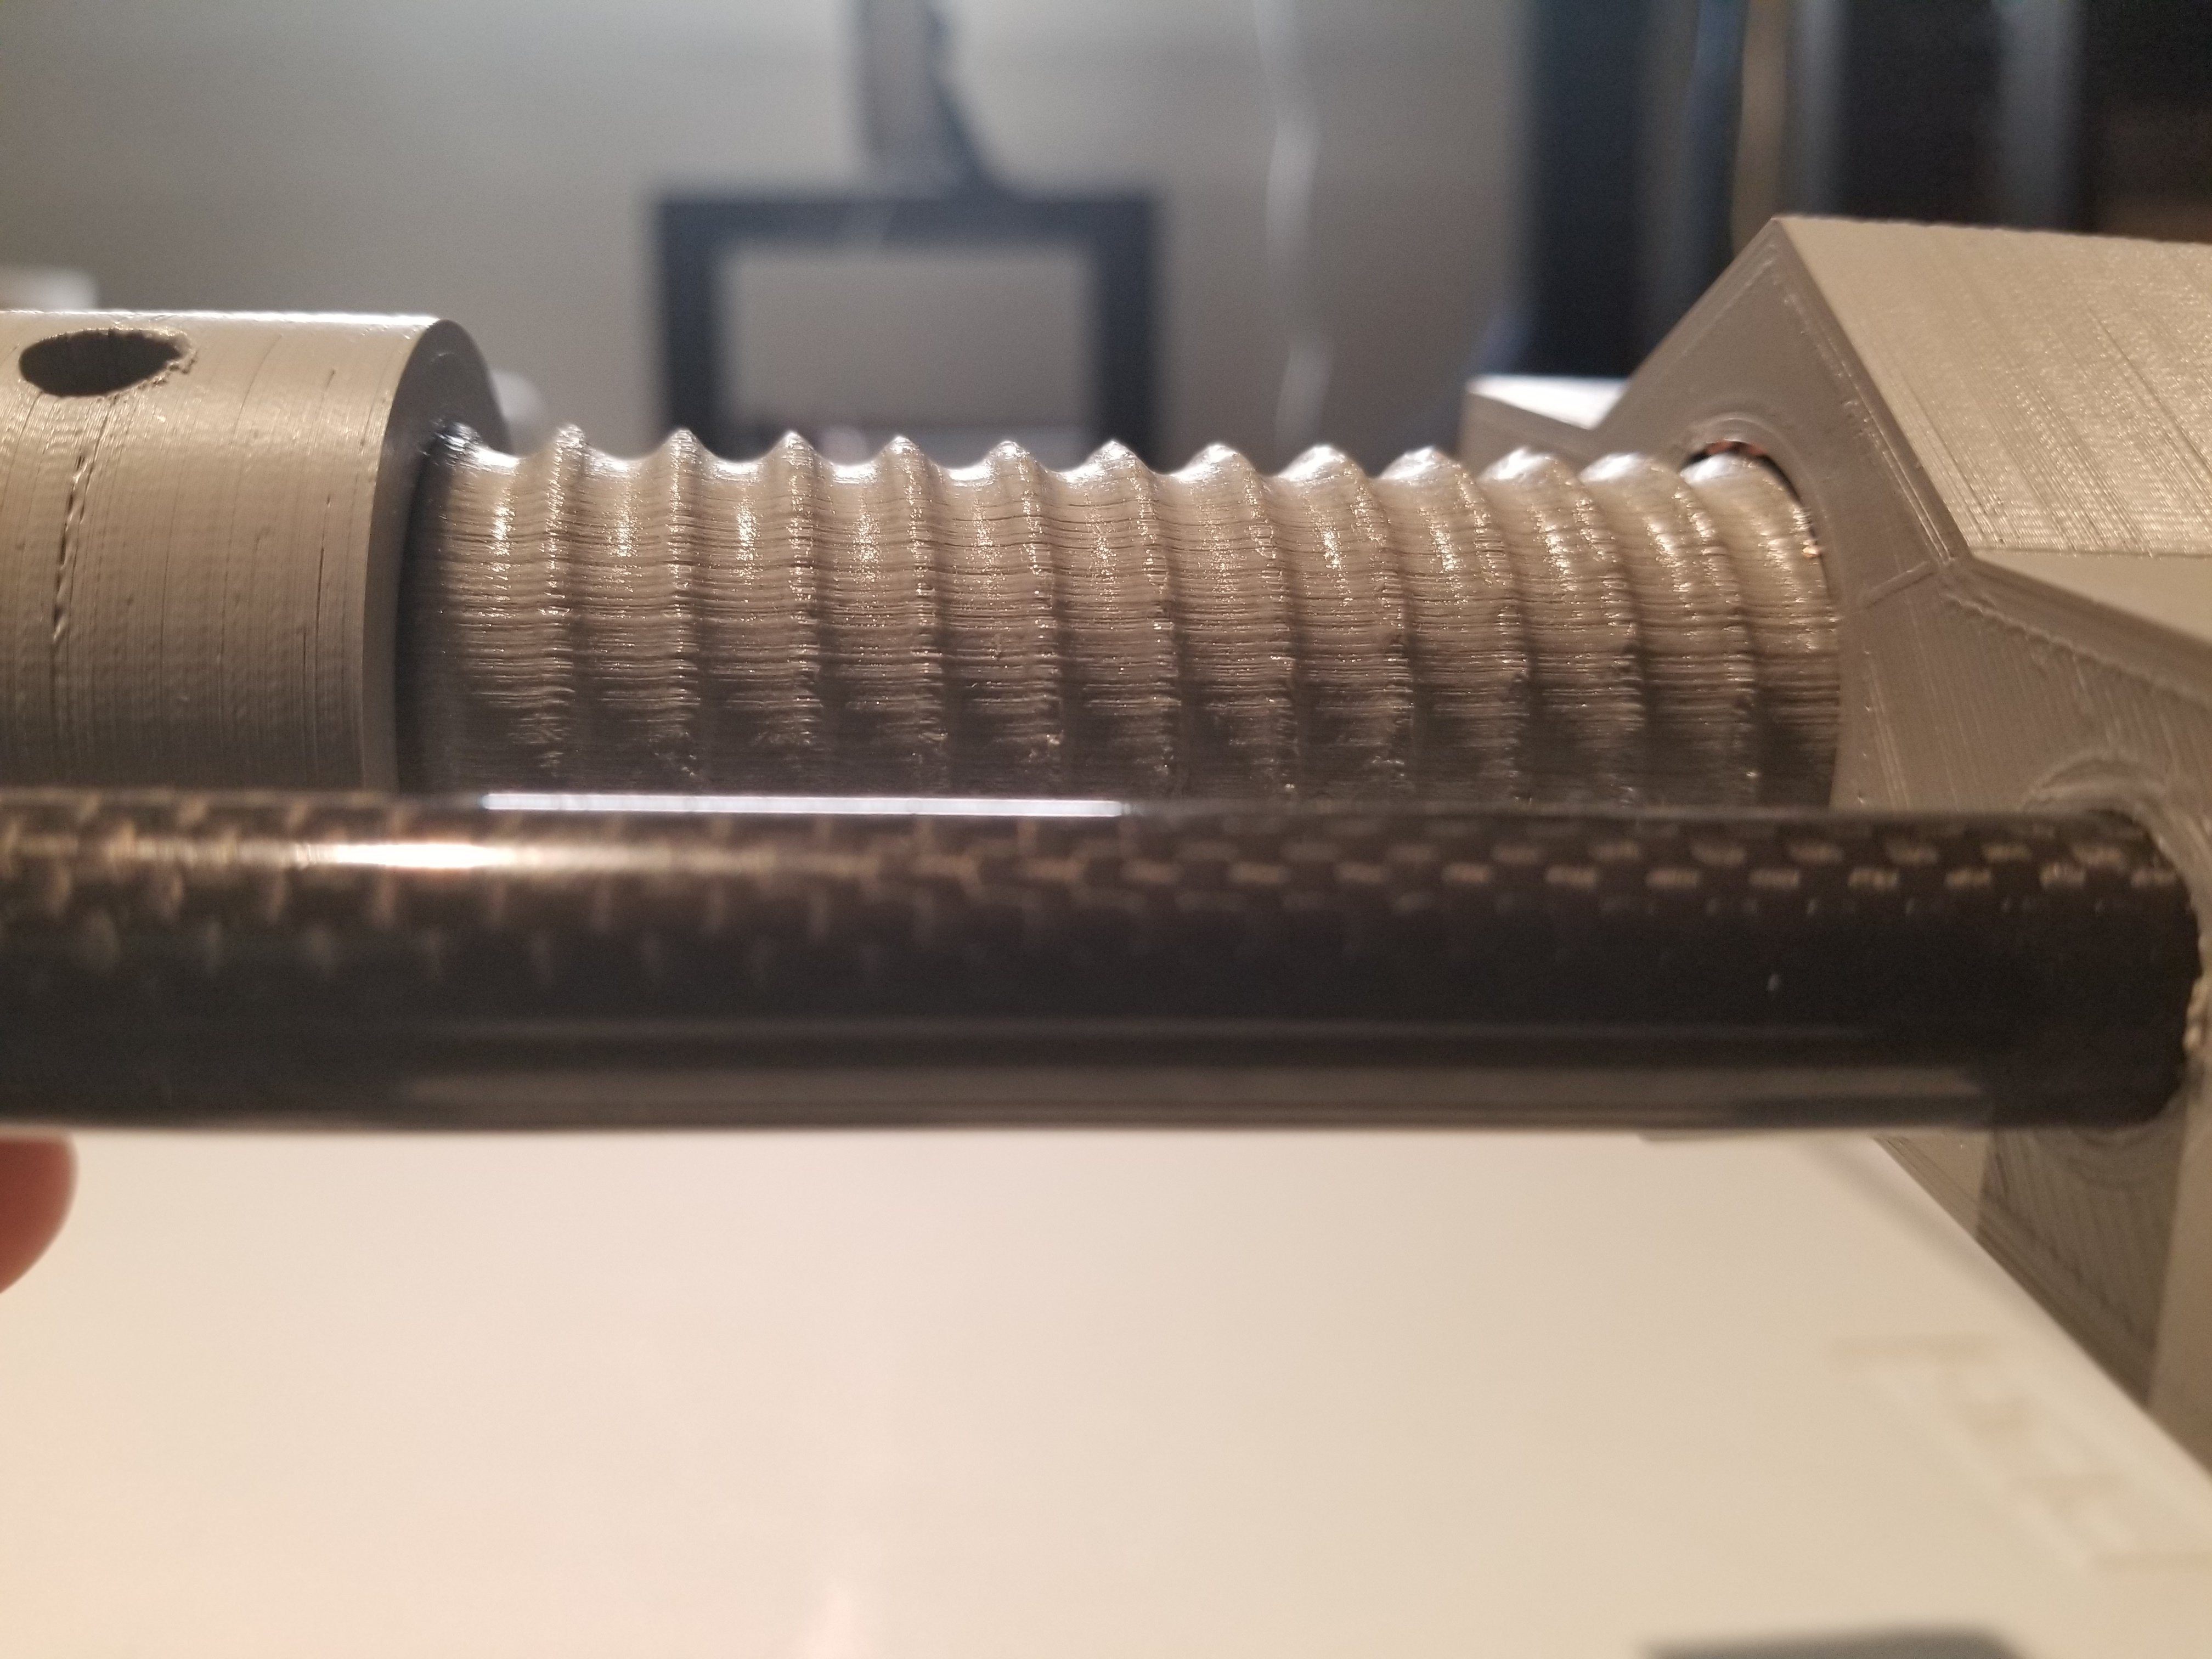
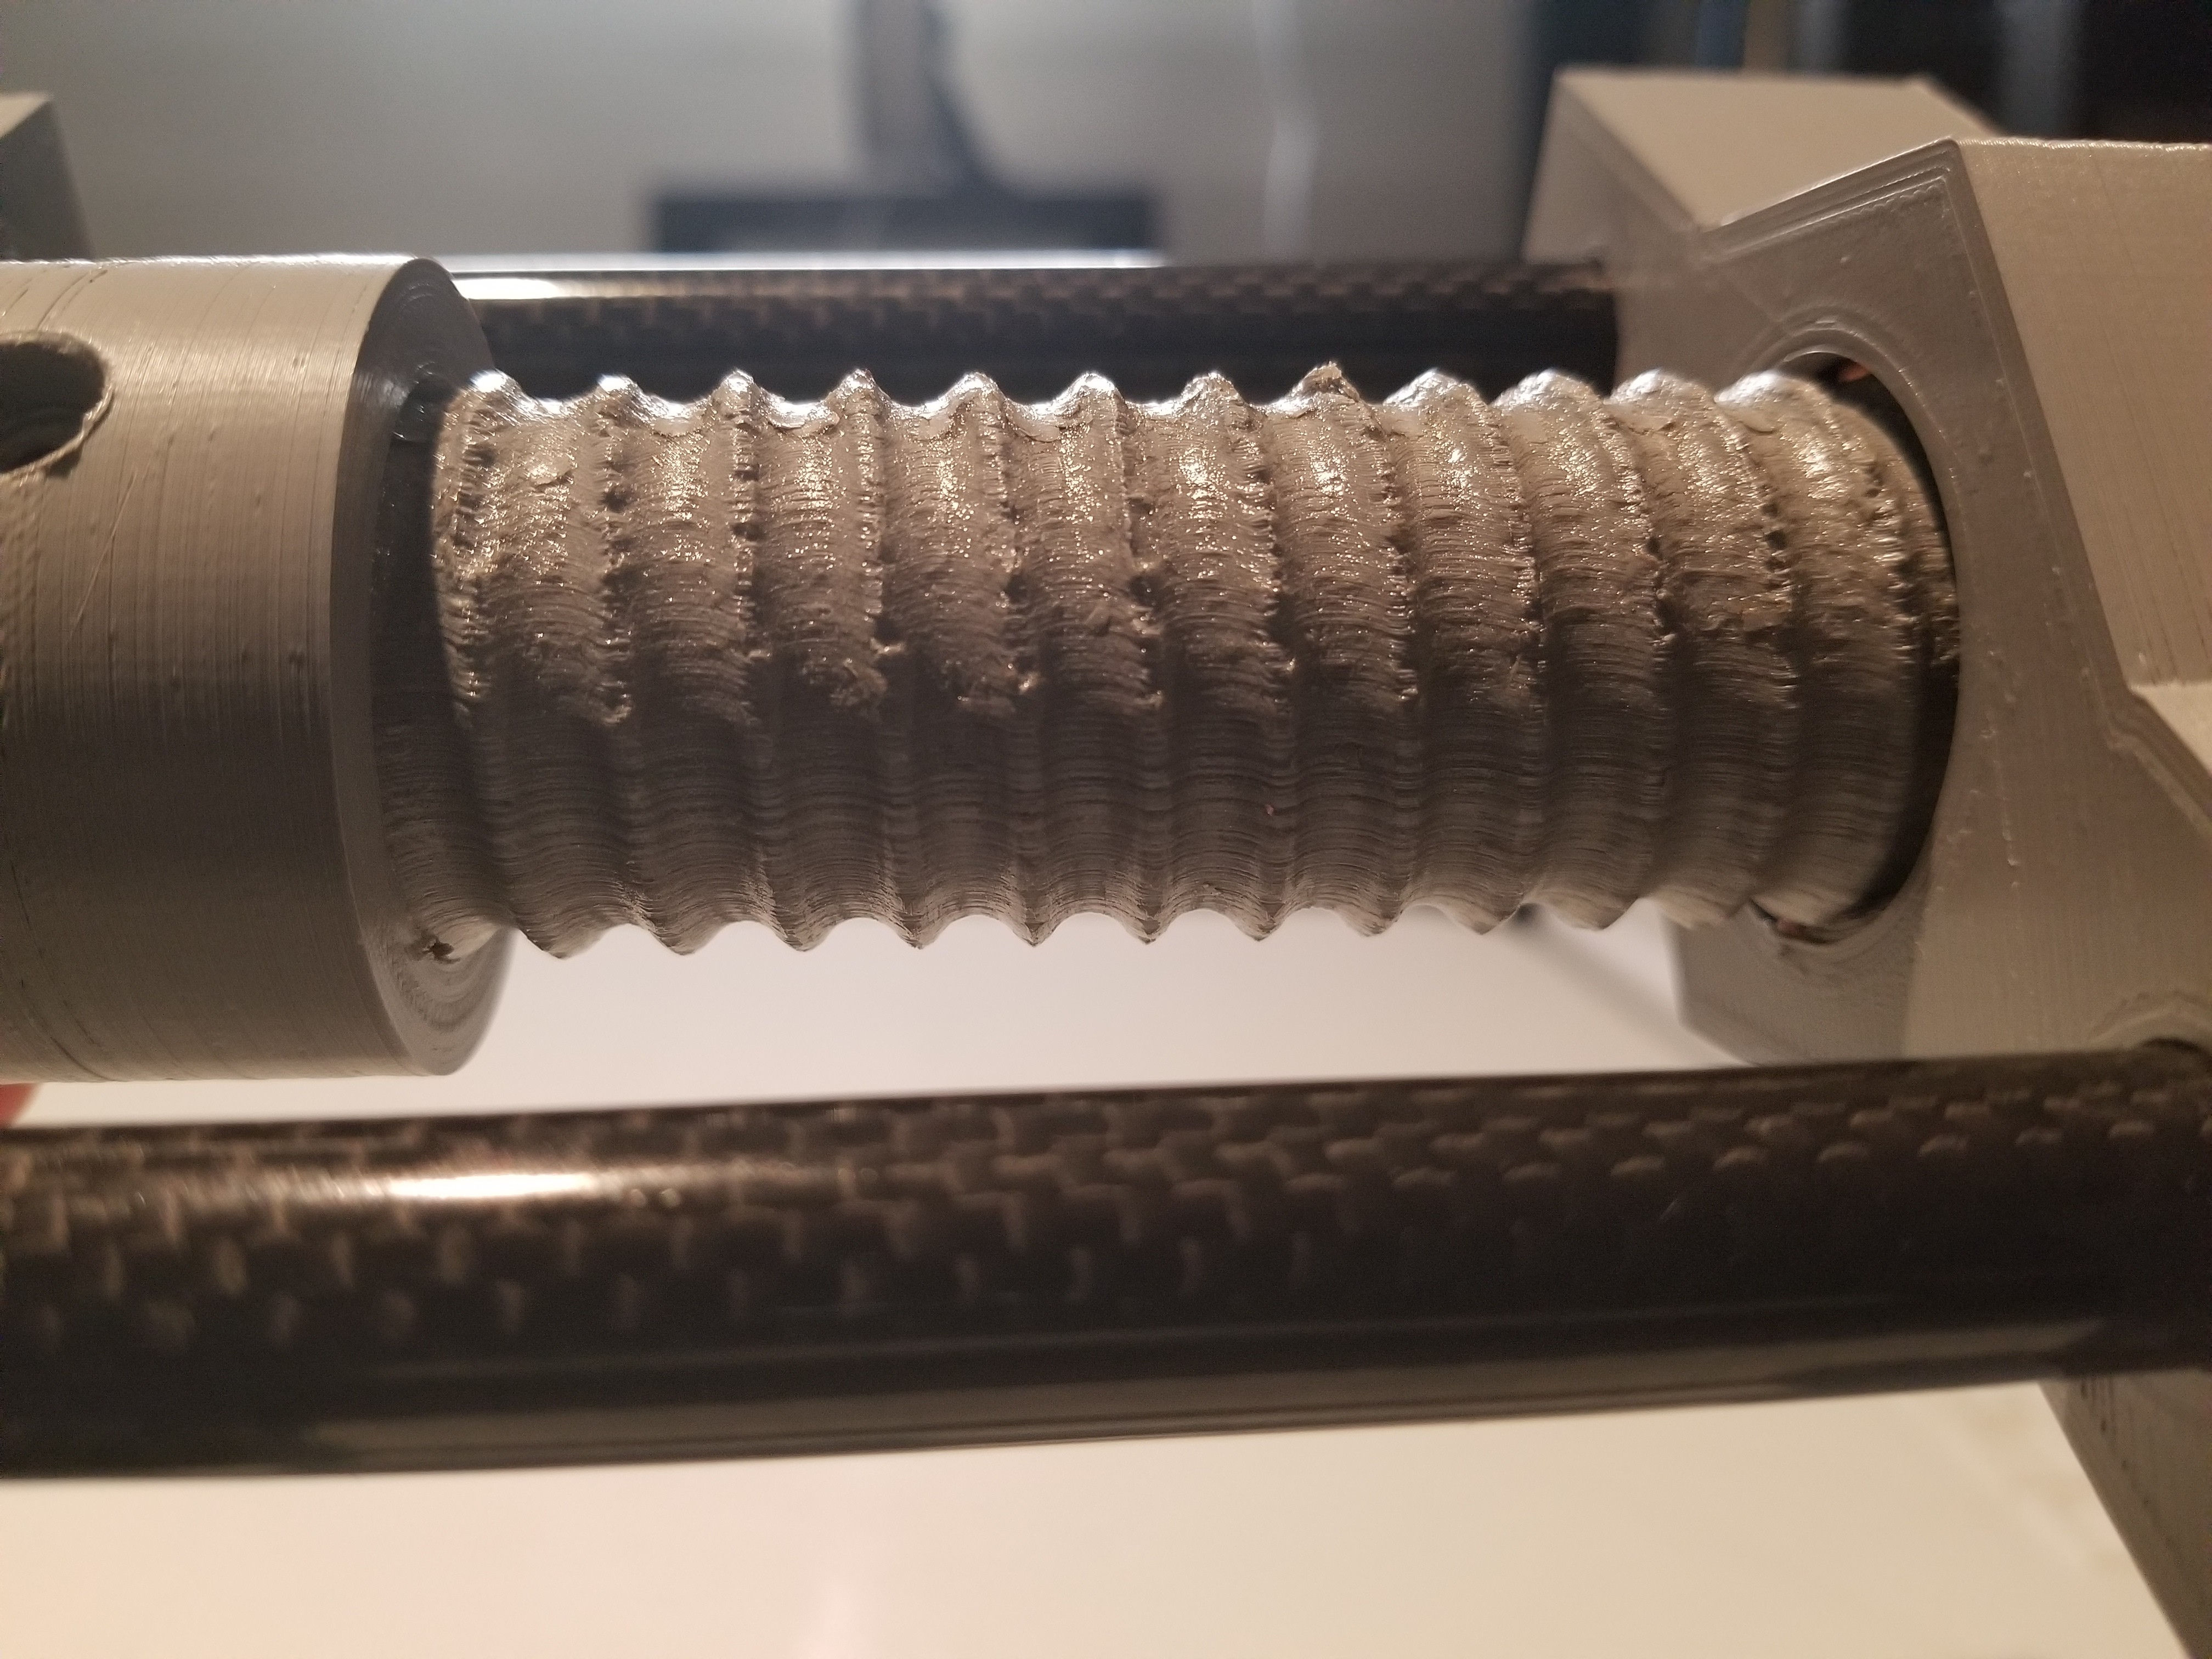
The stroke of the actuator is a bit wobbly, partly attributed to an uneven print surface. This was due to the print being performed horizontally, using support on one of the sides. The Wanhao i3 had a bit of trouble with layer separation the higher a print goes, so we will be leaving the printing of tall parts to our new delta printer.
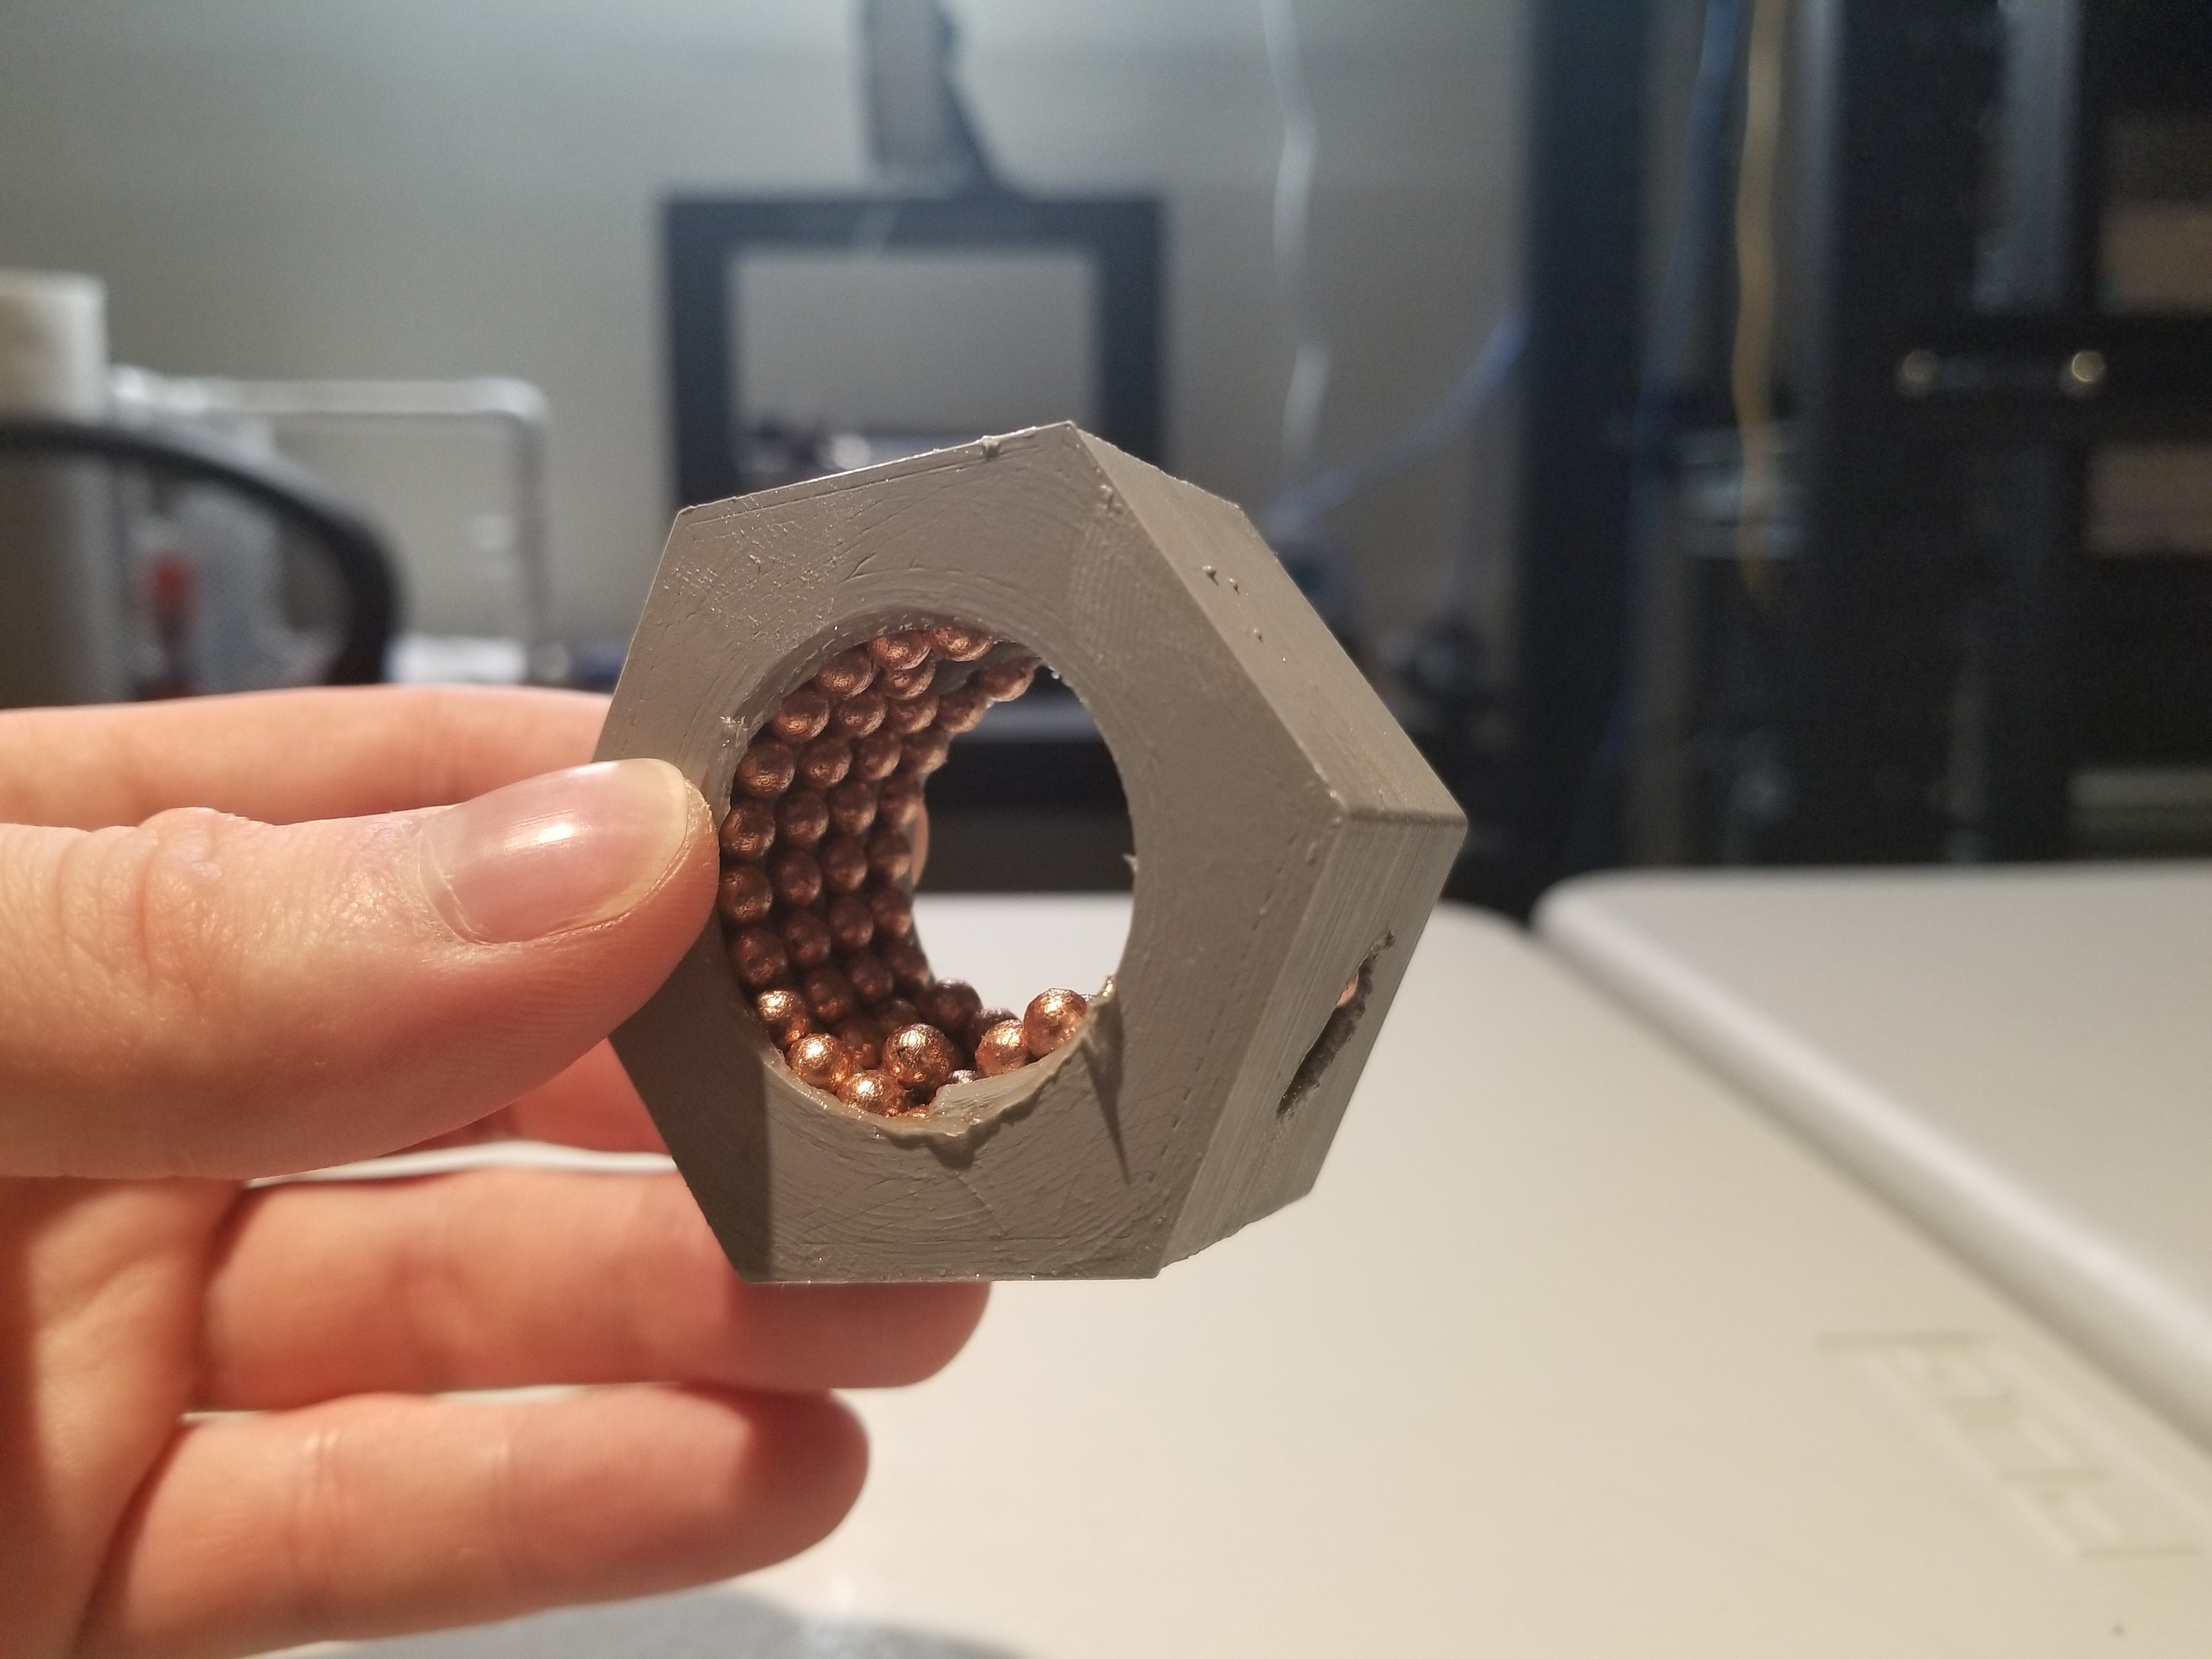
Also, the nut containing the ball bearings was not completely full, which may have resulted in some added backlash. This can be fixed by filling the nut completely with BBs.
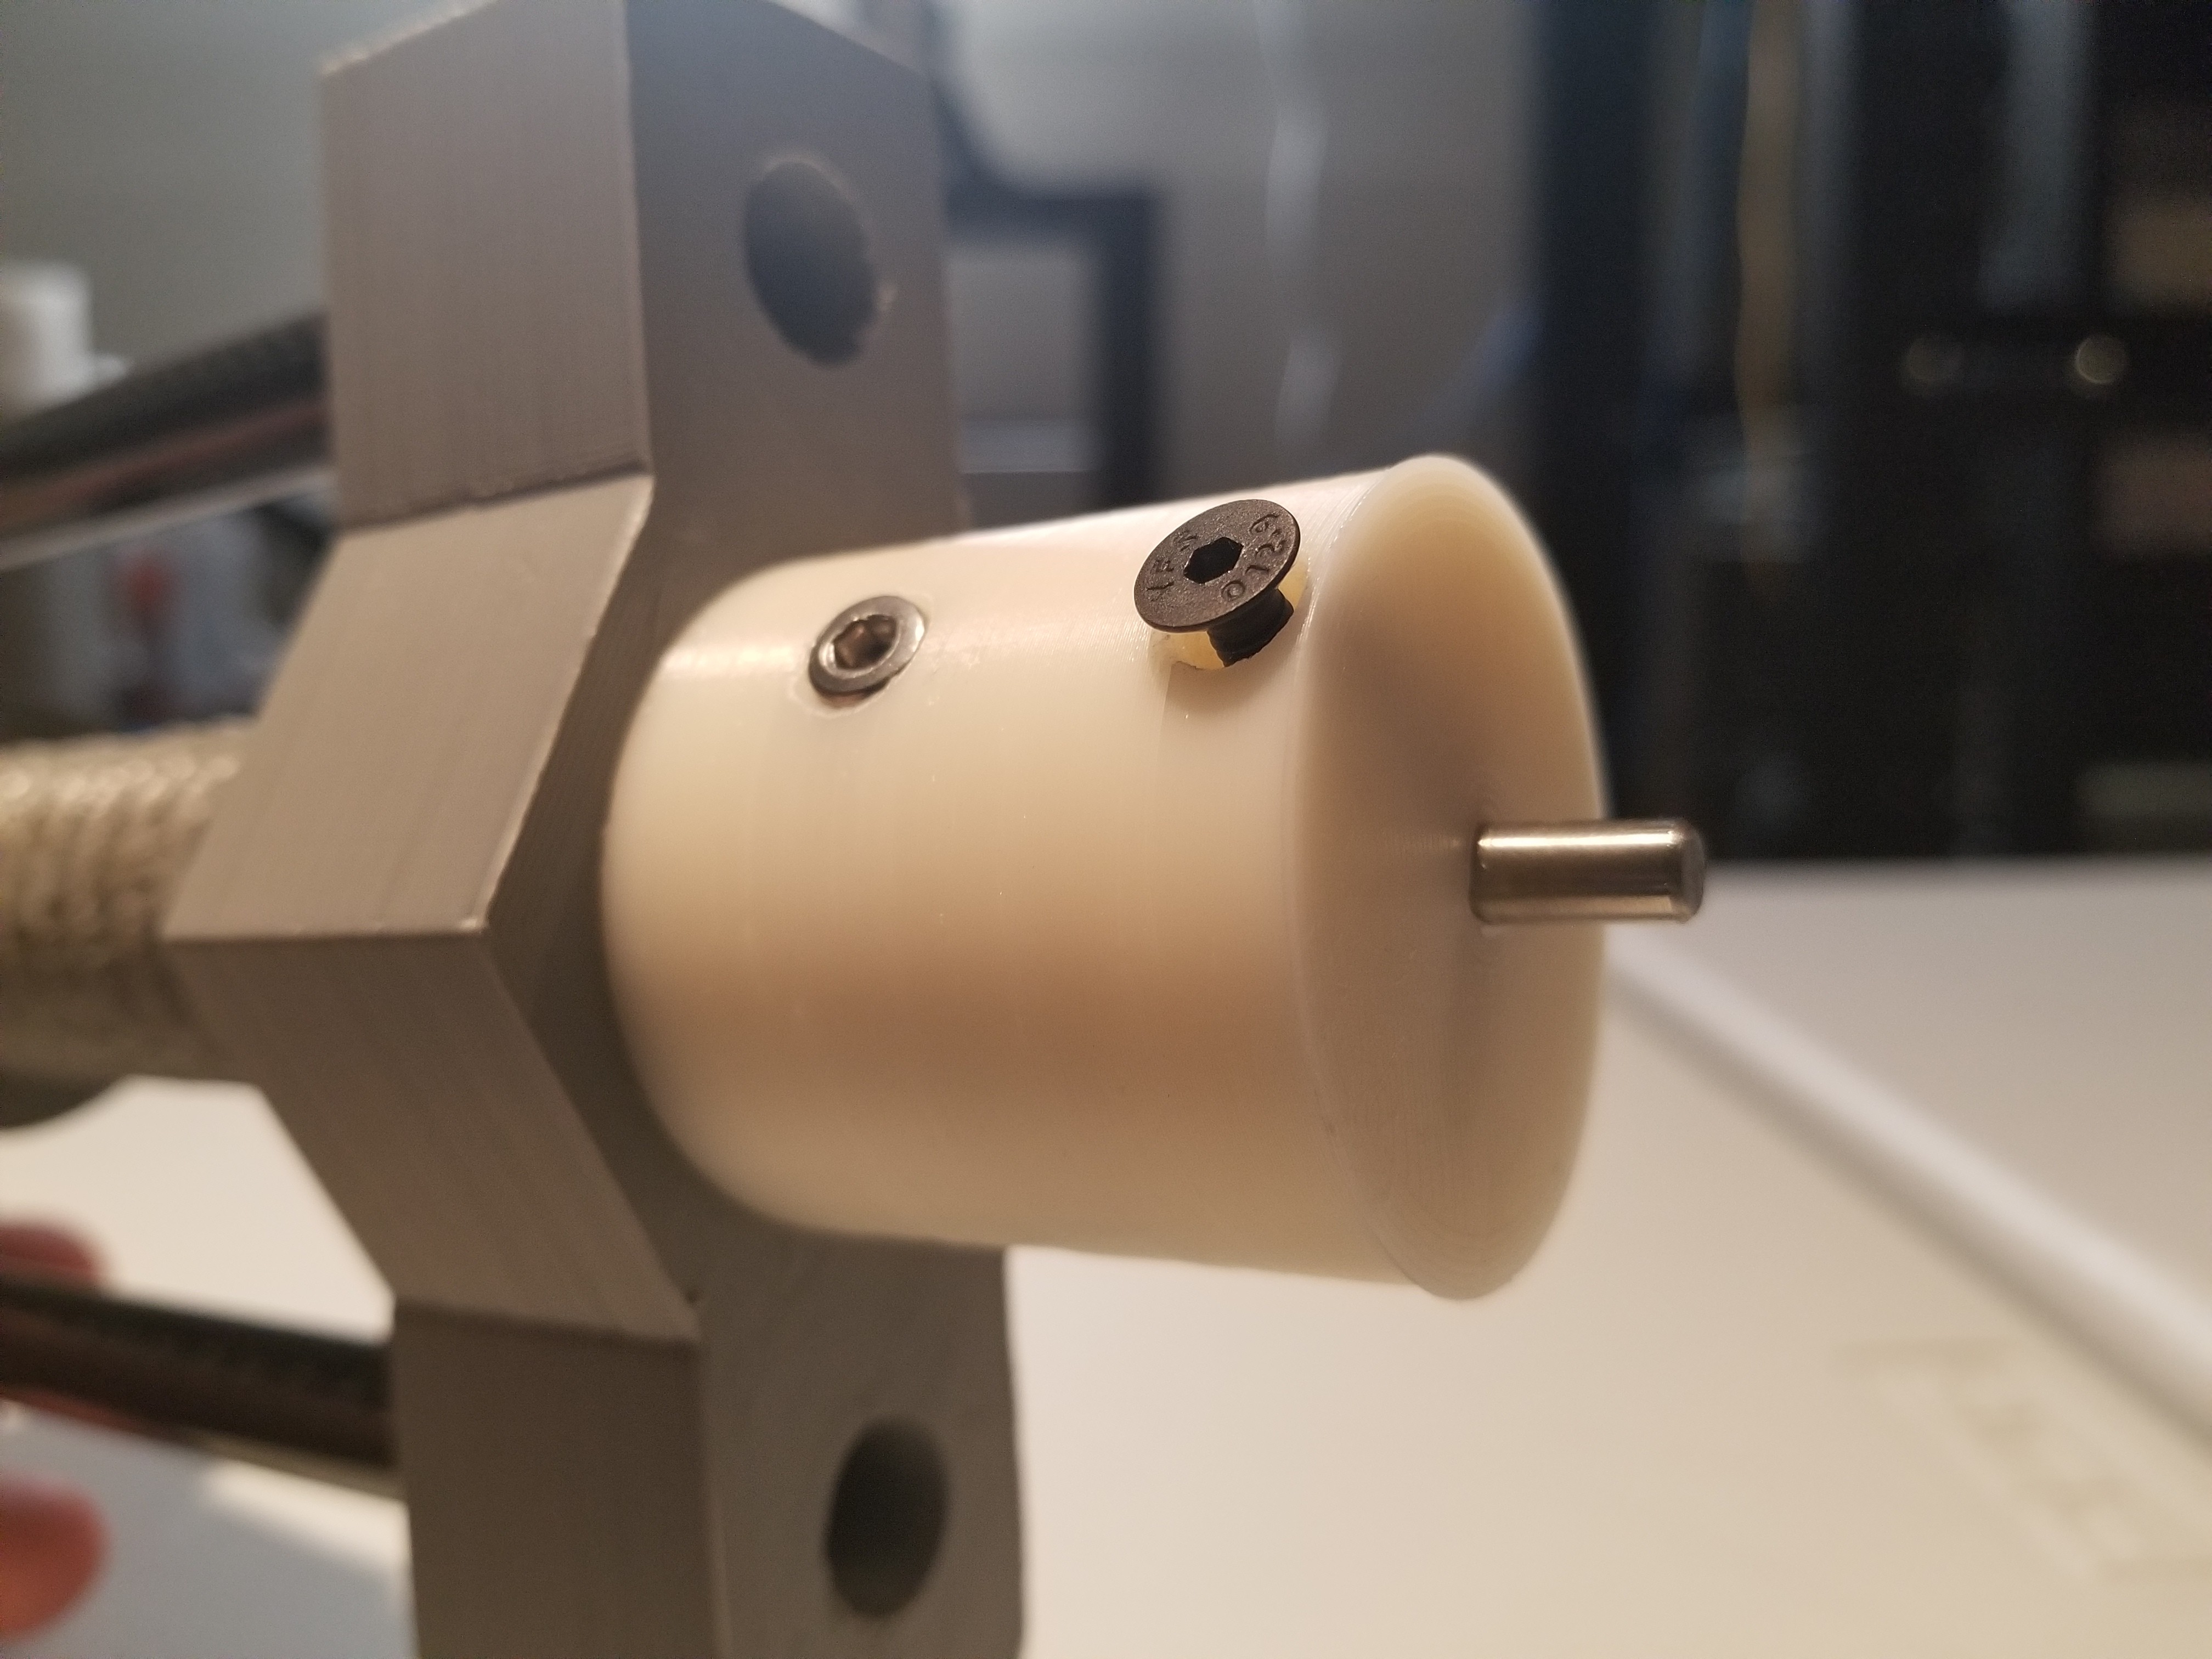
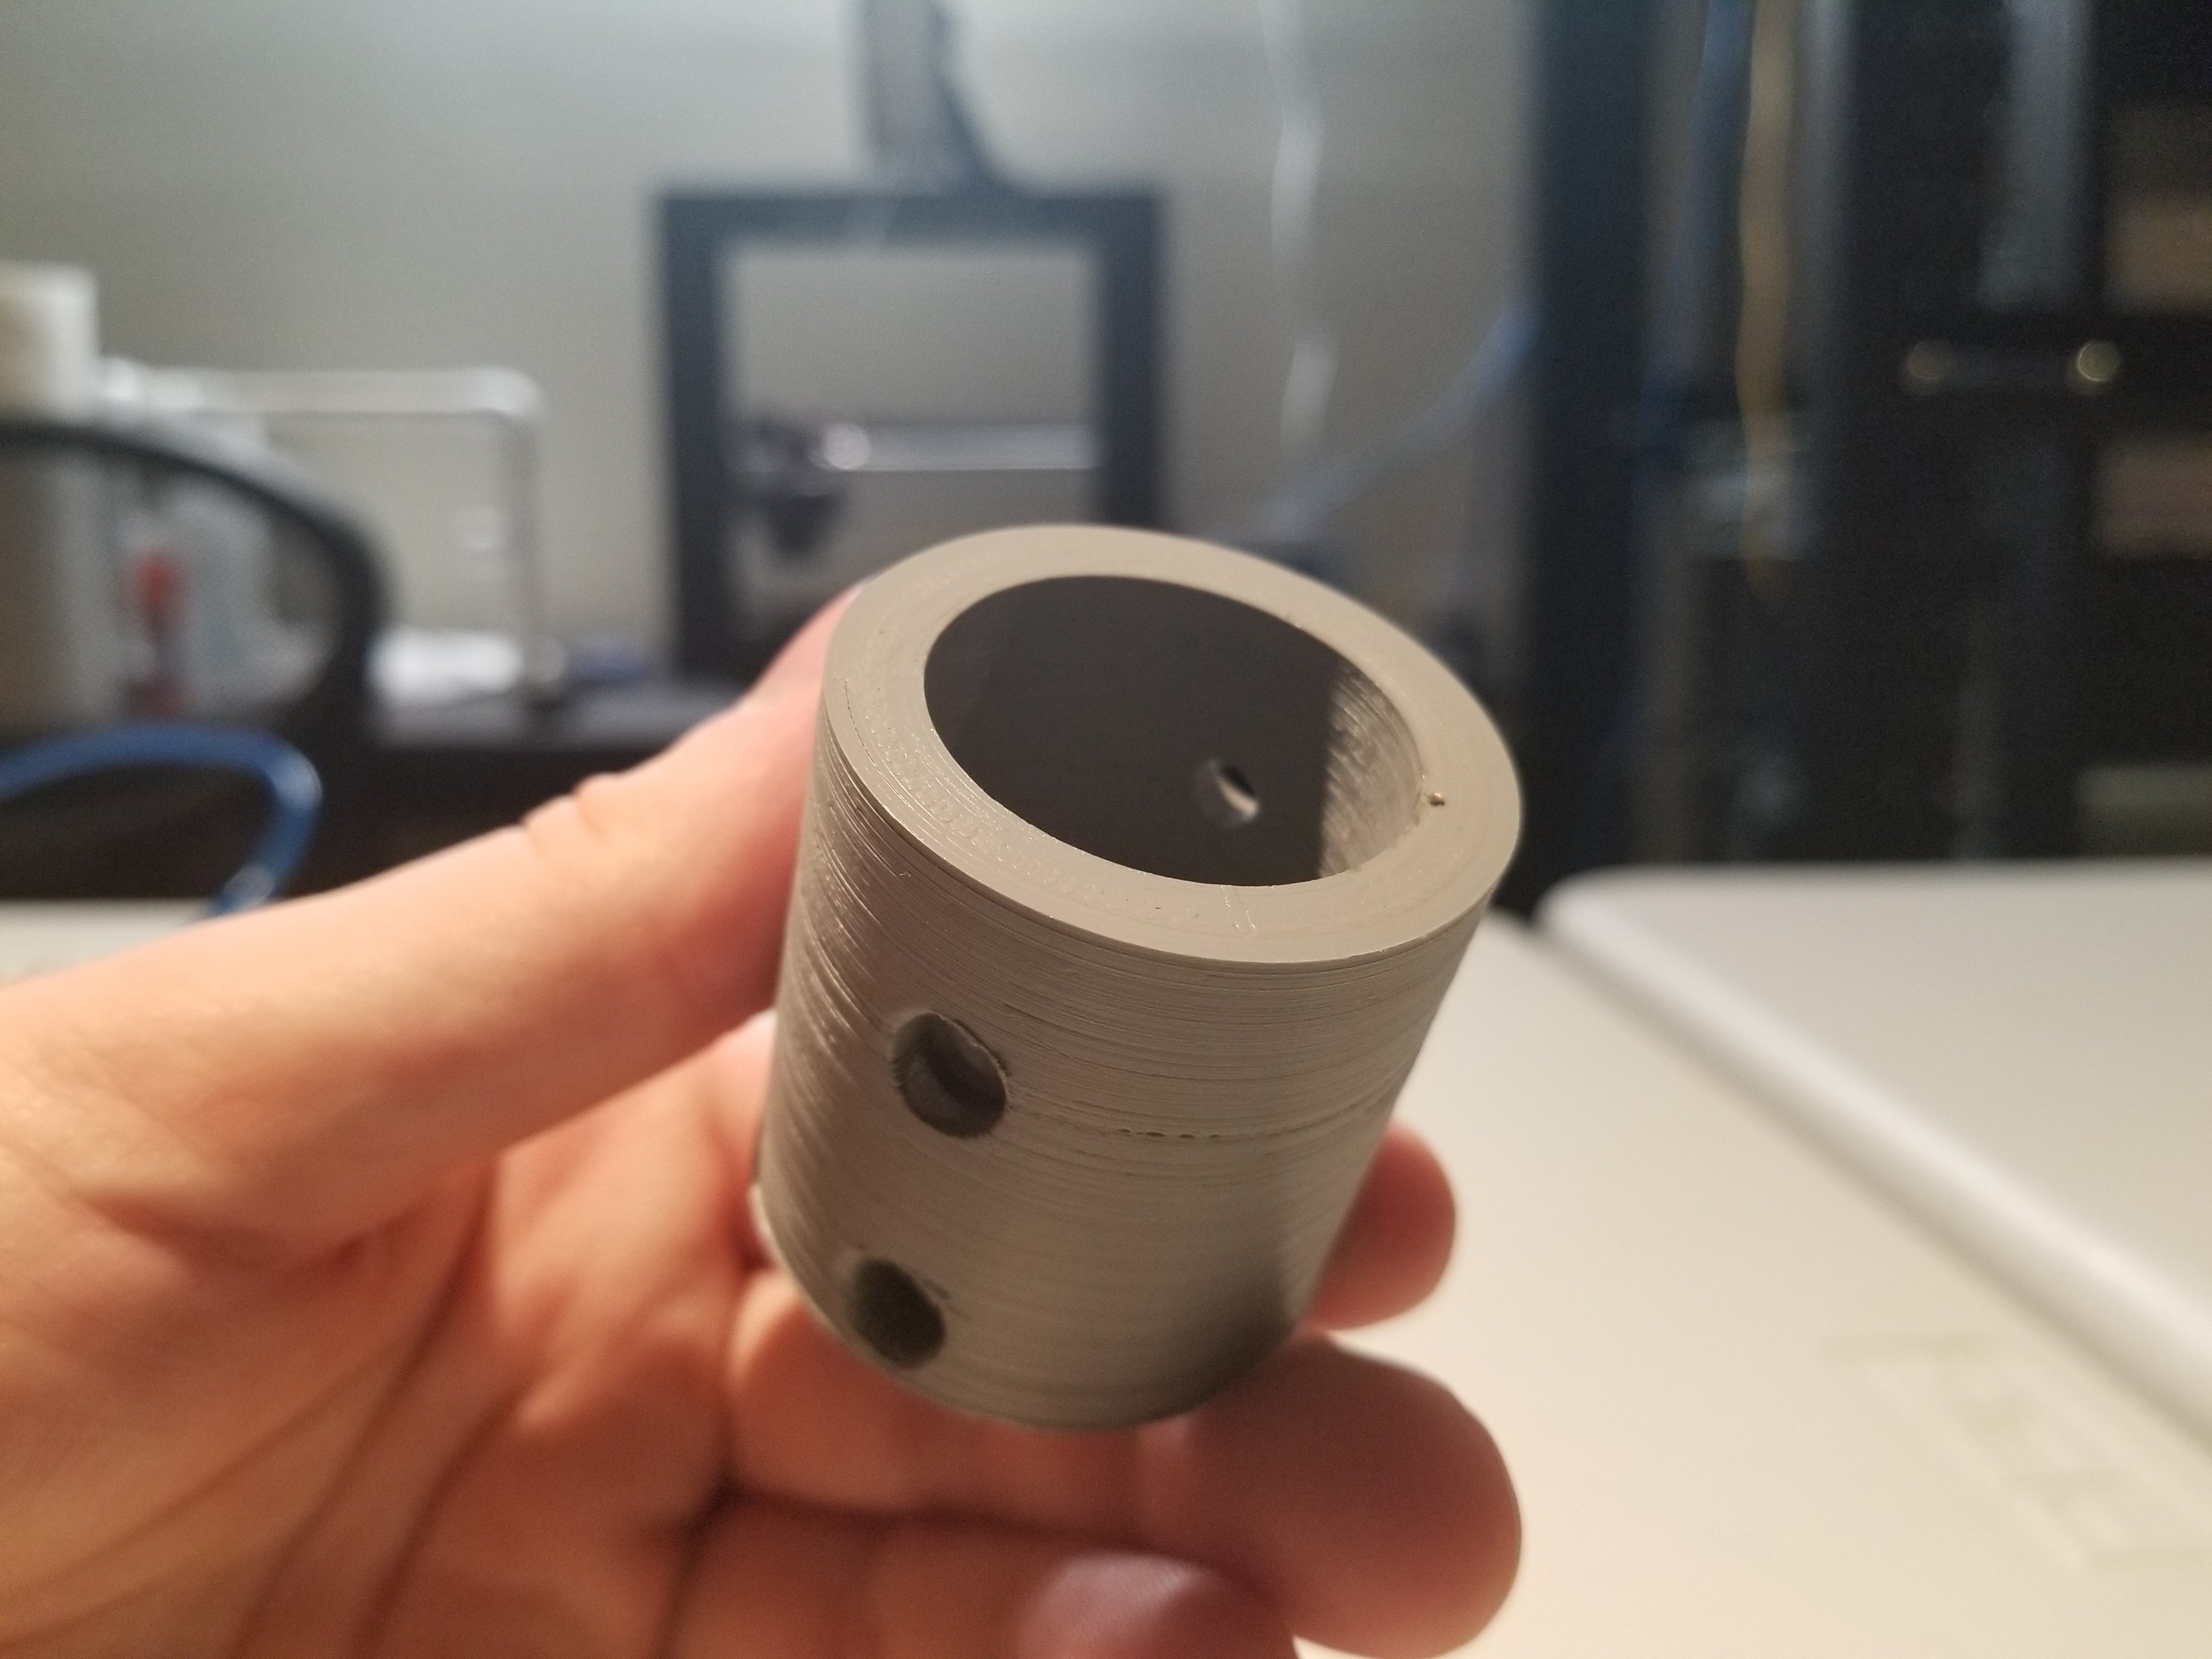
The improved motor coupler allows for secure attachment to the thread of the ballscrew, as well as easy fixation via set screw to the motor shaft. The coupler can be easily swapped based on the desired motor shaft size.
Overall, not too bad for a first prototype! We are looking forward to an improved second print, with some added features including endstop switches, and proper motorization.
Create an account to leave a comment. Already have an account? Log In.
Become a member to follow this project and never miss any updates