 chris.h


Parallel Robot Clock - Hackaday One Hertz Challenge
Project Summary
The Direct Drive Parallel Robot Clock uses a human capable 6-DoF parallel robot to create precise 1-second timekeeping. A 40mm ball moves clockwise through 60 pockets arranged in a 645mm diameter circle, advancing one position every second. The system executes a complex motion sequence combining vertical translation (75.932mm span) and rotation (6° per step). Each second, the platform drops at -5.0g, breaking contact with the ball, rotates to align with the next pocket, then catches the free-falling ball with minimal impact using calculated trajectories. Motion control runs on a Teensy 4.1 at 3003Hz over Ethernet, with real-time feedback from an ARK Forward Kinematics Unit. The catch trajectory uses acceleration control for speed, while the return uses snap-controlled motion for smoothness.
Finally, a clock that requires a PhD to set the time.How It Works
The Physics
The magic happens in two distinct phases:
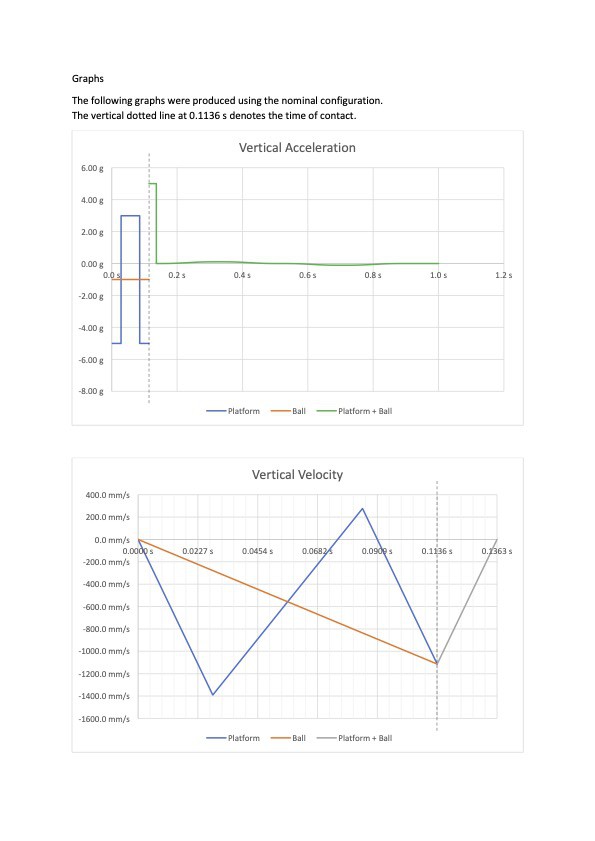
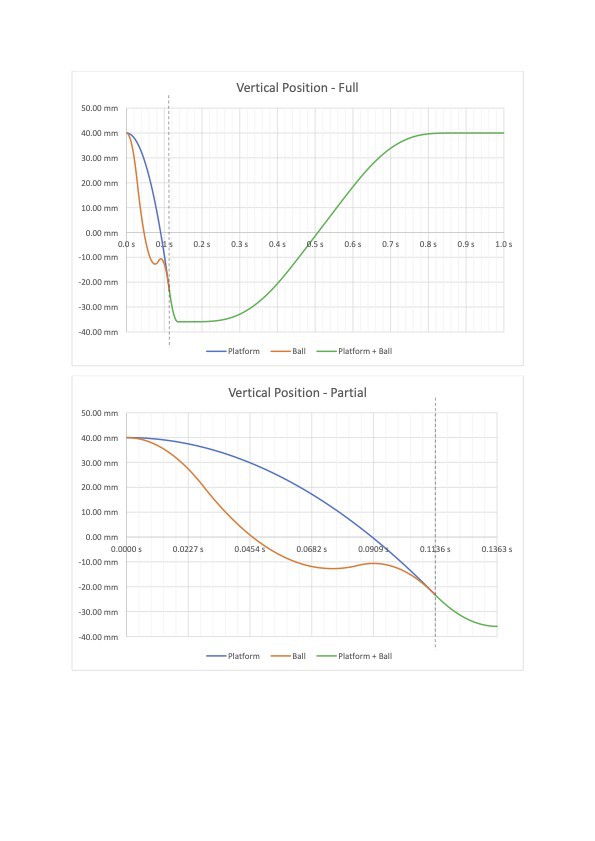
Catch Trajectory (0.000s - 0.136s):
- Platform drops at -5.0g, breaking contact with the 40mm ball
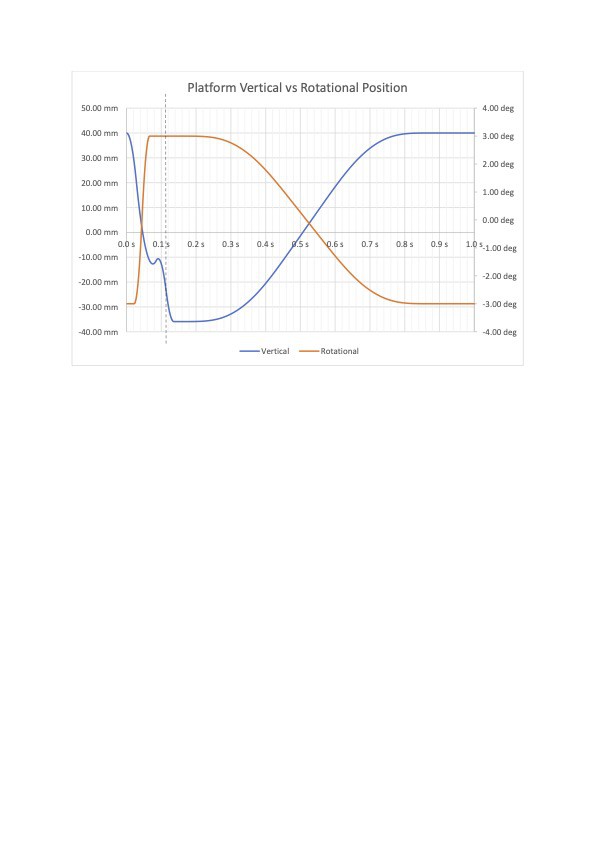
- Ball falls freely at -1.0g while platform rotates 6° to align with next pocket
- Platform reverses direction (+3.0g briefly, then -5.0g again)
- Calculated timing ensures both platform and ball have identical velocities at contact
- Minimal-impact catch at t=0.114s, followed by +5.0g deceleration to complete stop
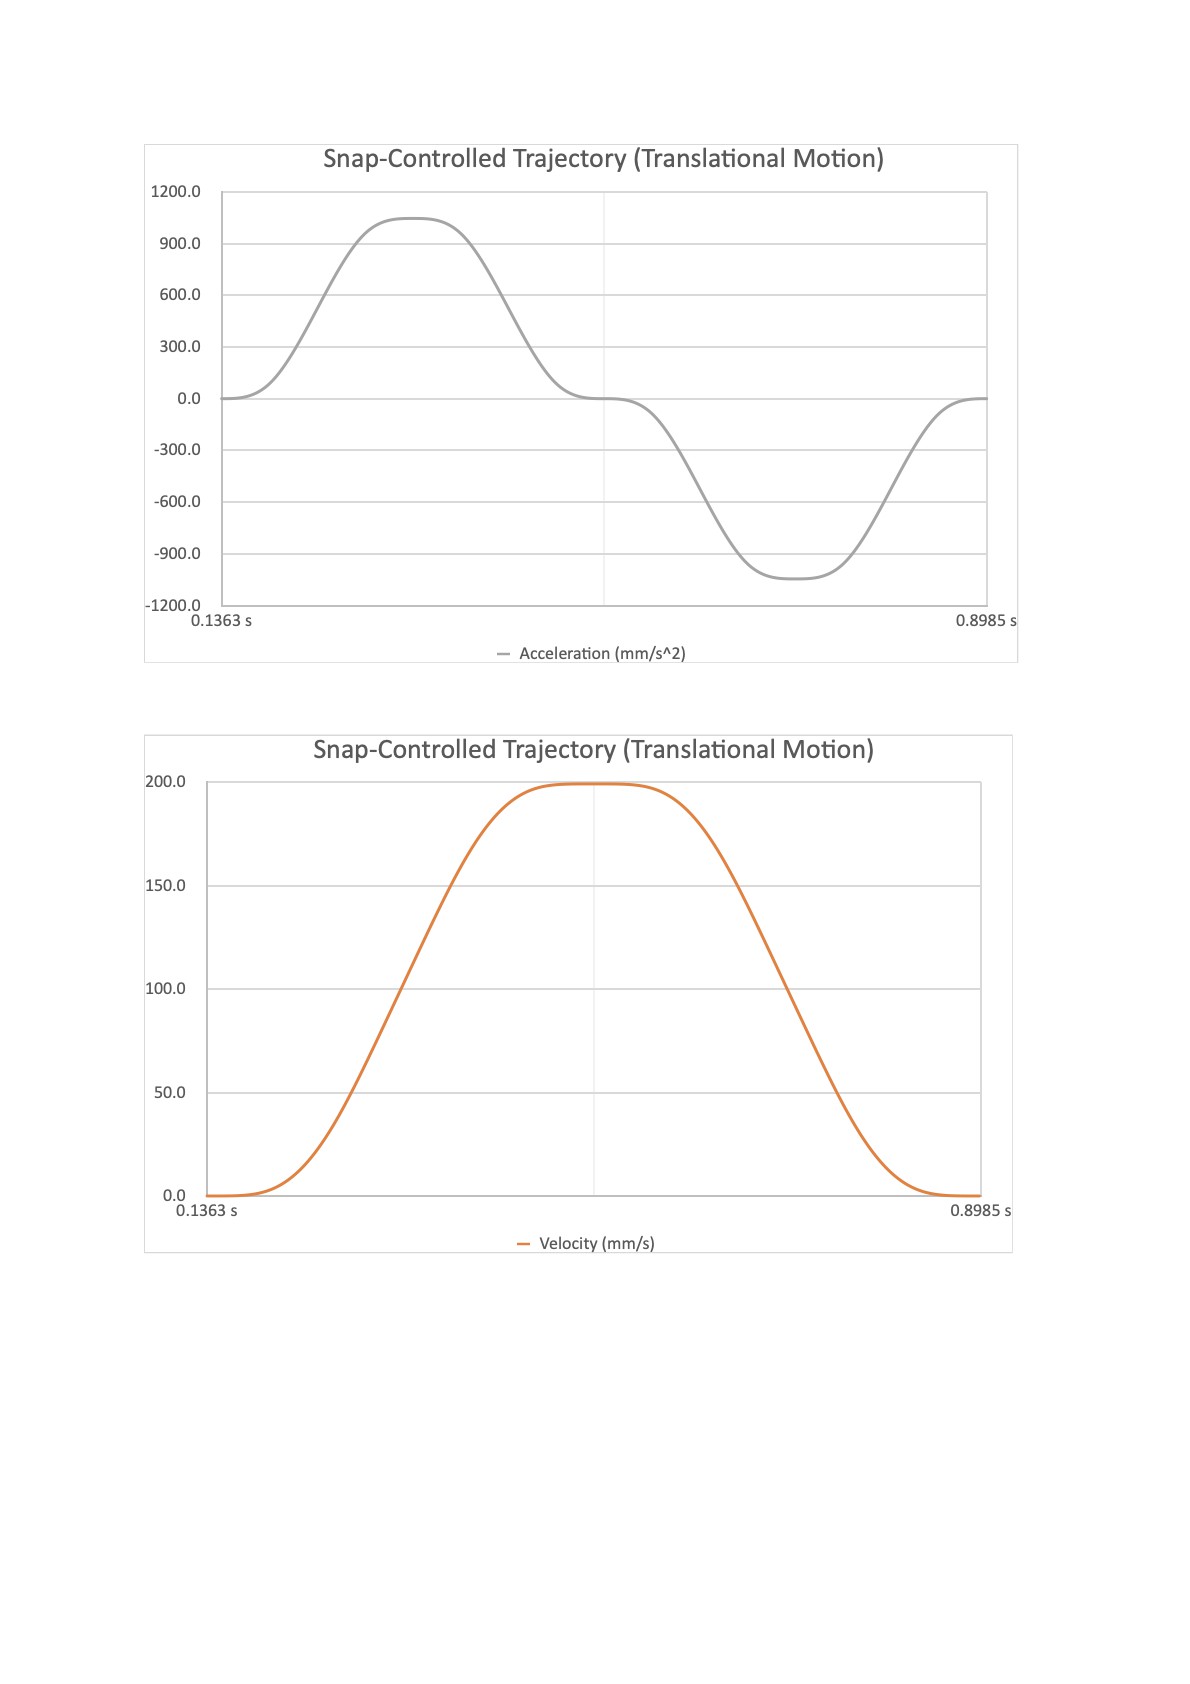
Return Trajectory (0.136s - 0.898s):
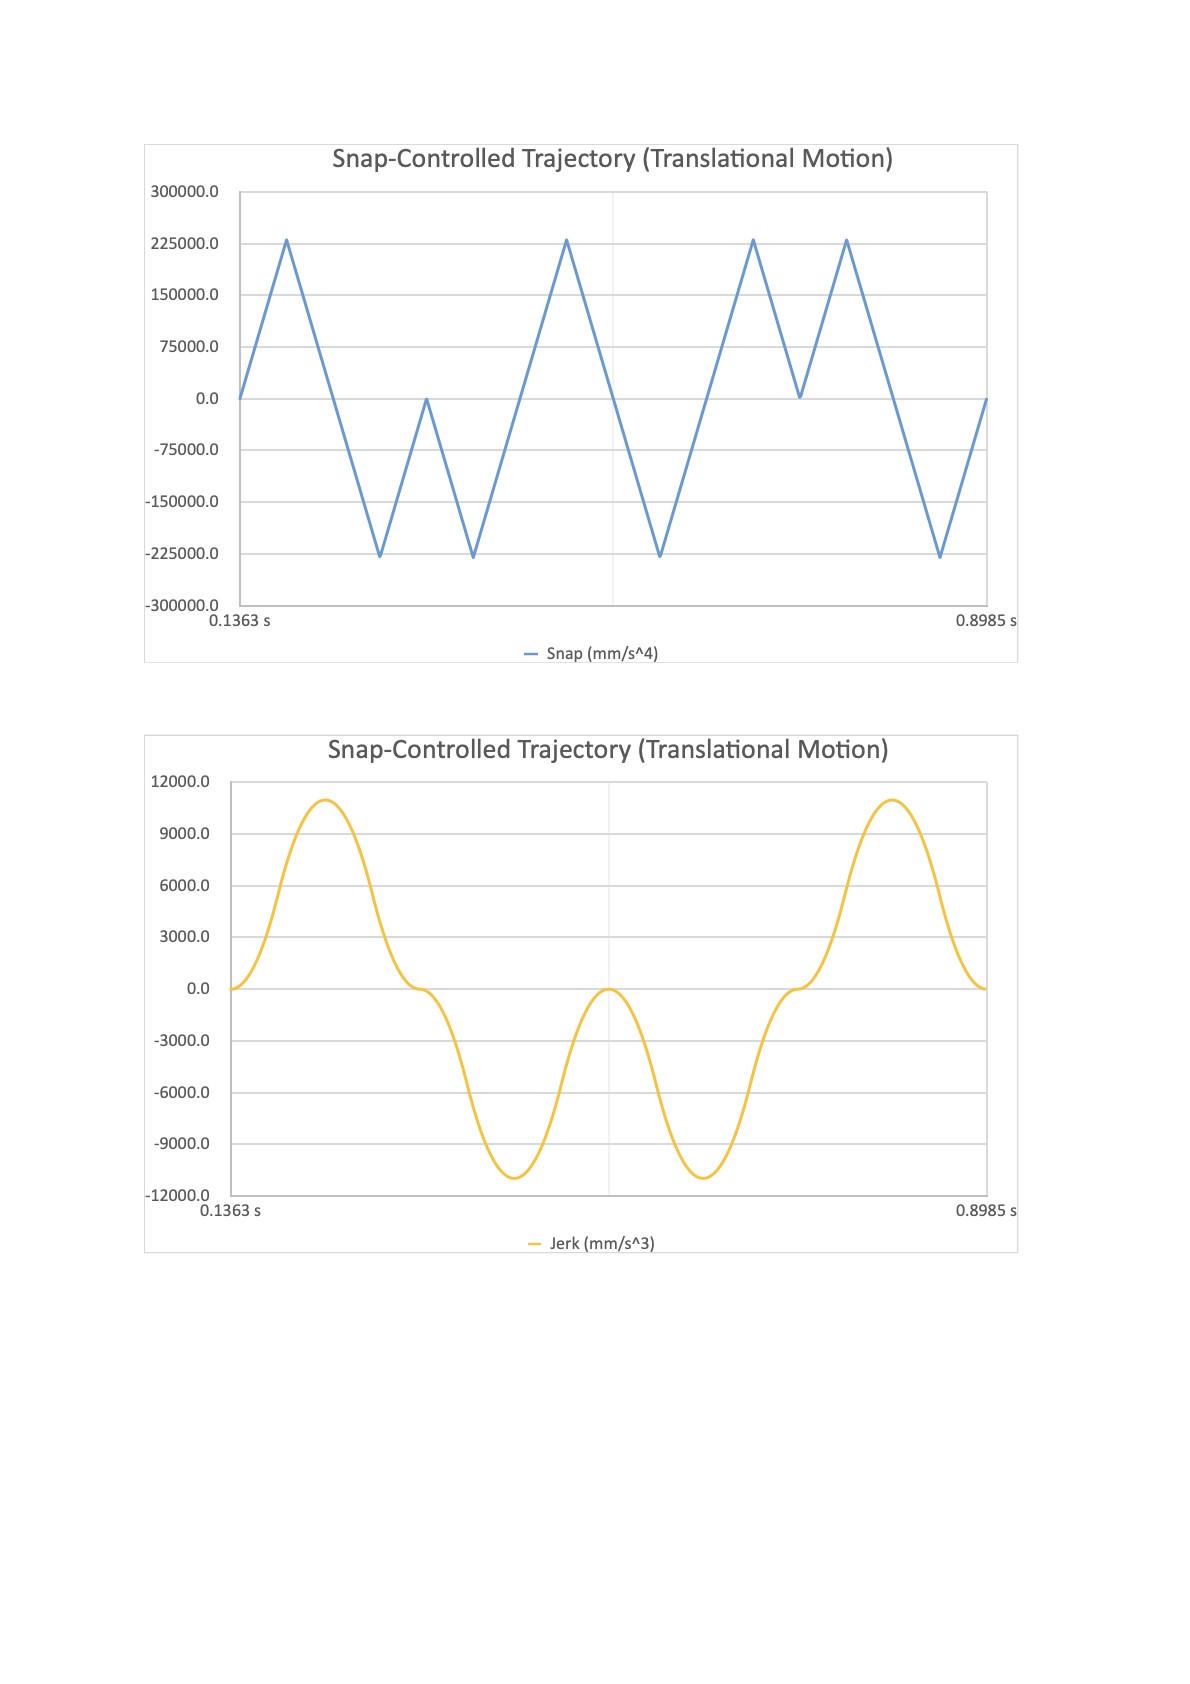
- Smooth snap-controlled motion returns platform and ball to starting position
- Uses advanced S-curve trajectory planning with kinematic constraints
- Acceleration, jerk, and snap are all continuously controlled for seamless motion
Technical Specifications
- Clock Face: 60 pockets in 645mm diameter circle (6° angular spacing)
- Motion Range: +40.000mm to -35.932mm vertical, ±3° rotation
- Control Rate: 3003 Hz command rate via 100M Ethernet/UDP
- Feedback: ARK Forward Kinematics Unit providing sub-millisecond response
- Precision: 1-second resolution over 60-second repeating cycle
Control Parameters (Online Adjustable)
- g - Gravity Acceleration Coefficient (tuned to 1.0475)
- tC - Time of Contact (0.1136s nominal)
- K - Max Translational Acceleration Coefficient (5.0g)
- tY - Rotation Start Time (tuned to 0.017s)
- aY - Max Rotational Acceleration (12000°/s²)
Innovation Highlights
Advanced Motion Control
This project showcases cutting-edge open source robotics. The snap-controlled trajectory algorithm provides Online, Kinematically Constrained, Snap-Continuous S-Curve Trajectory Planning - technology typically reserved for high-end industrial applications.
Real-Time Performance
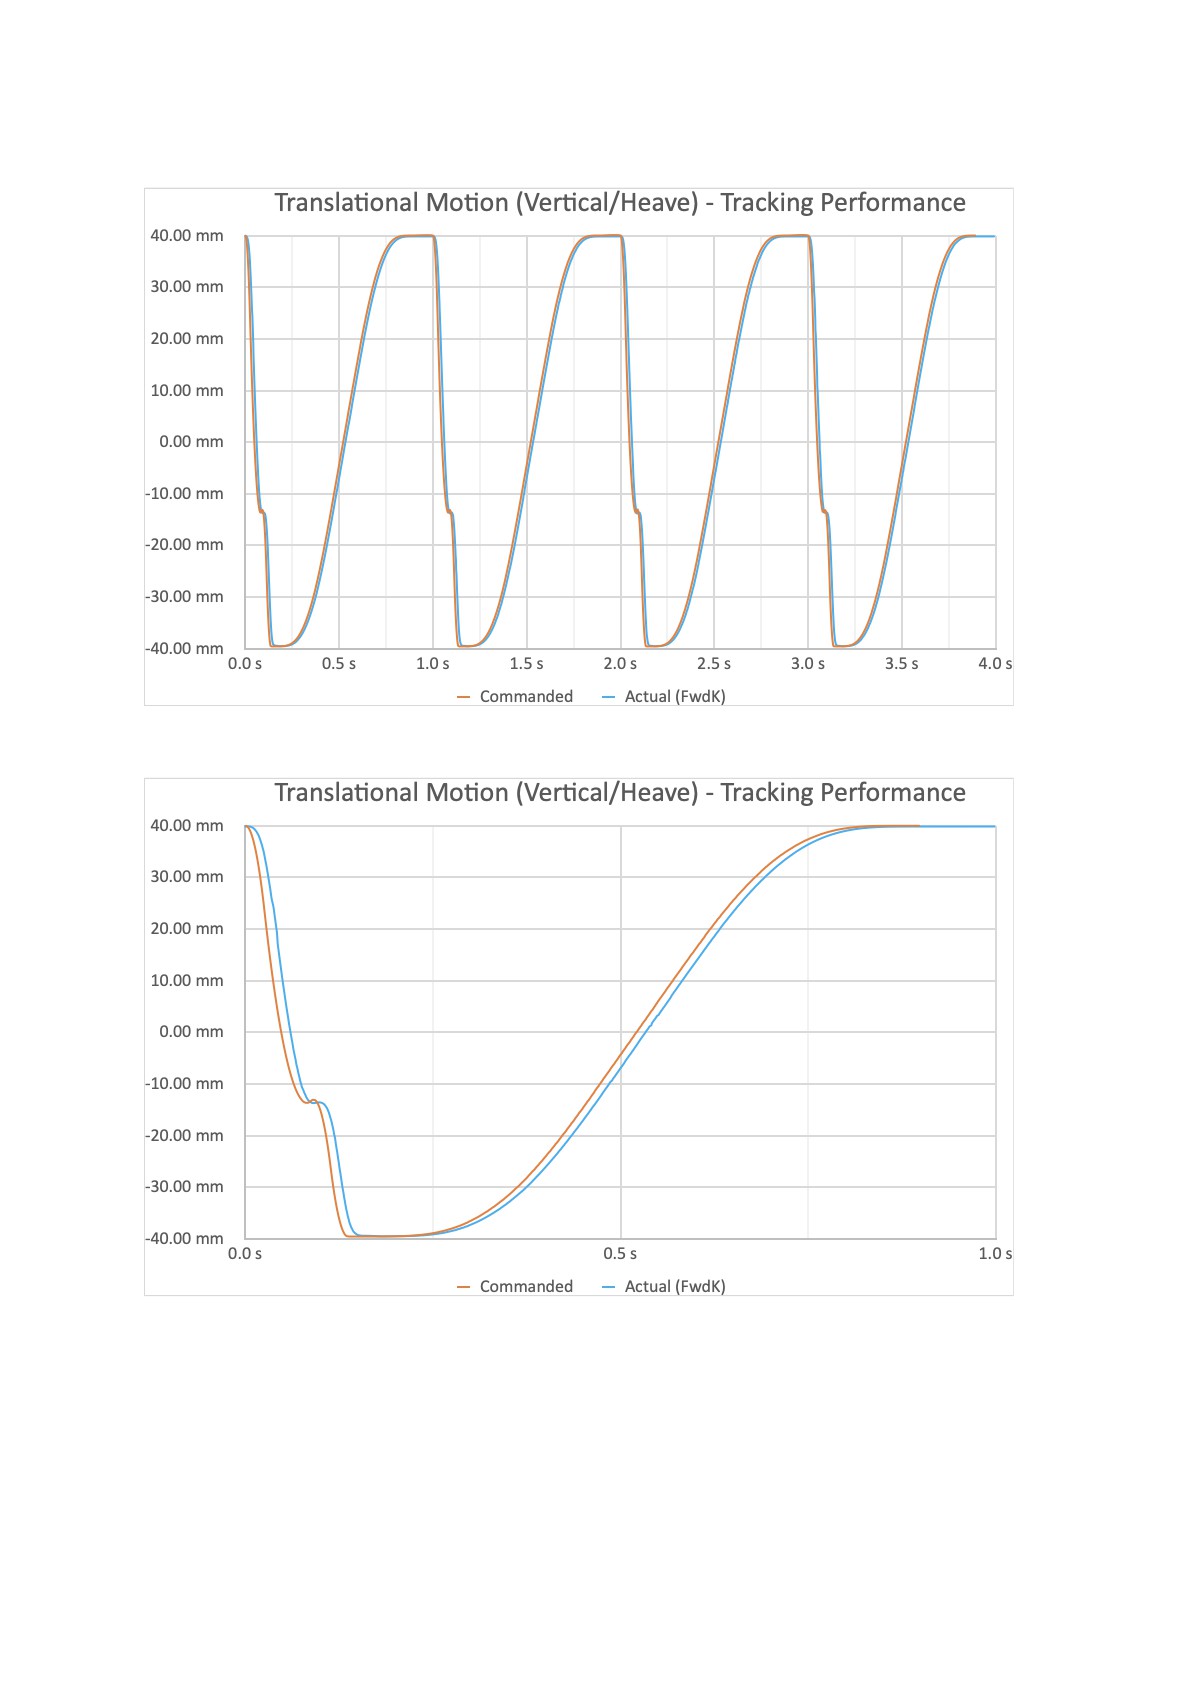
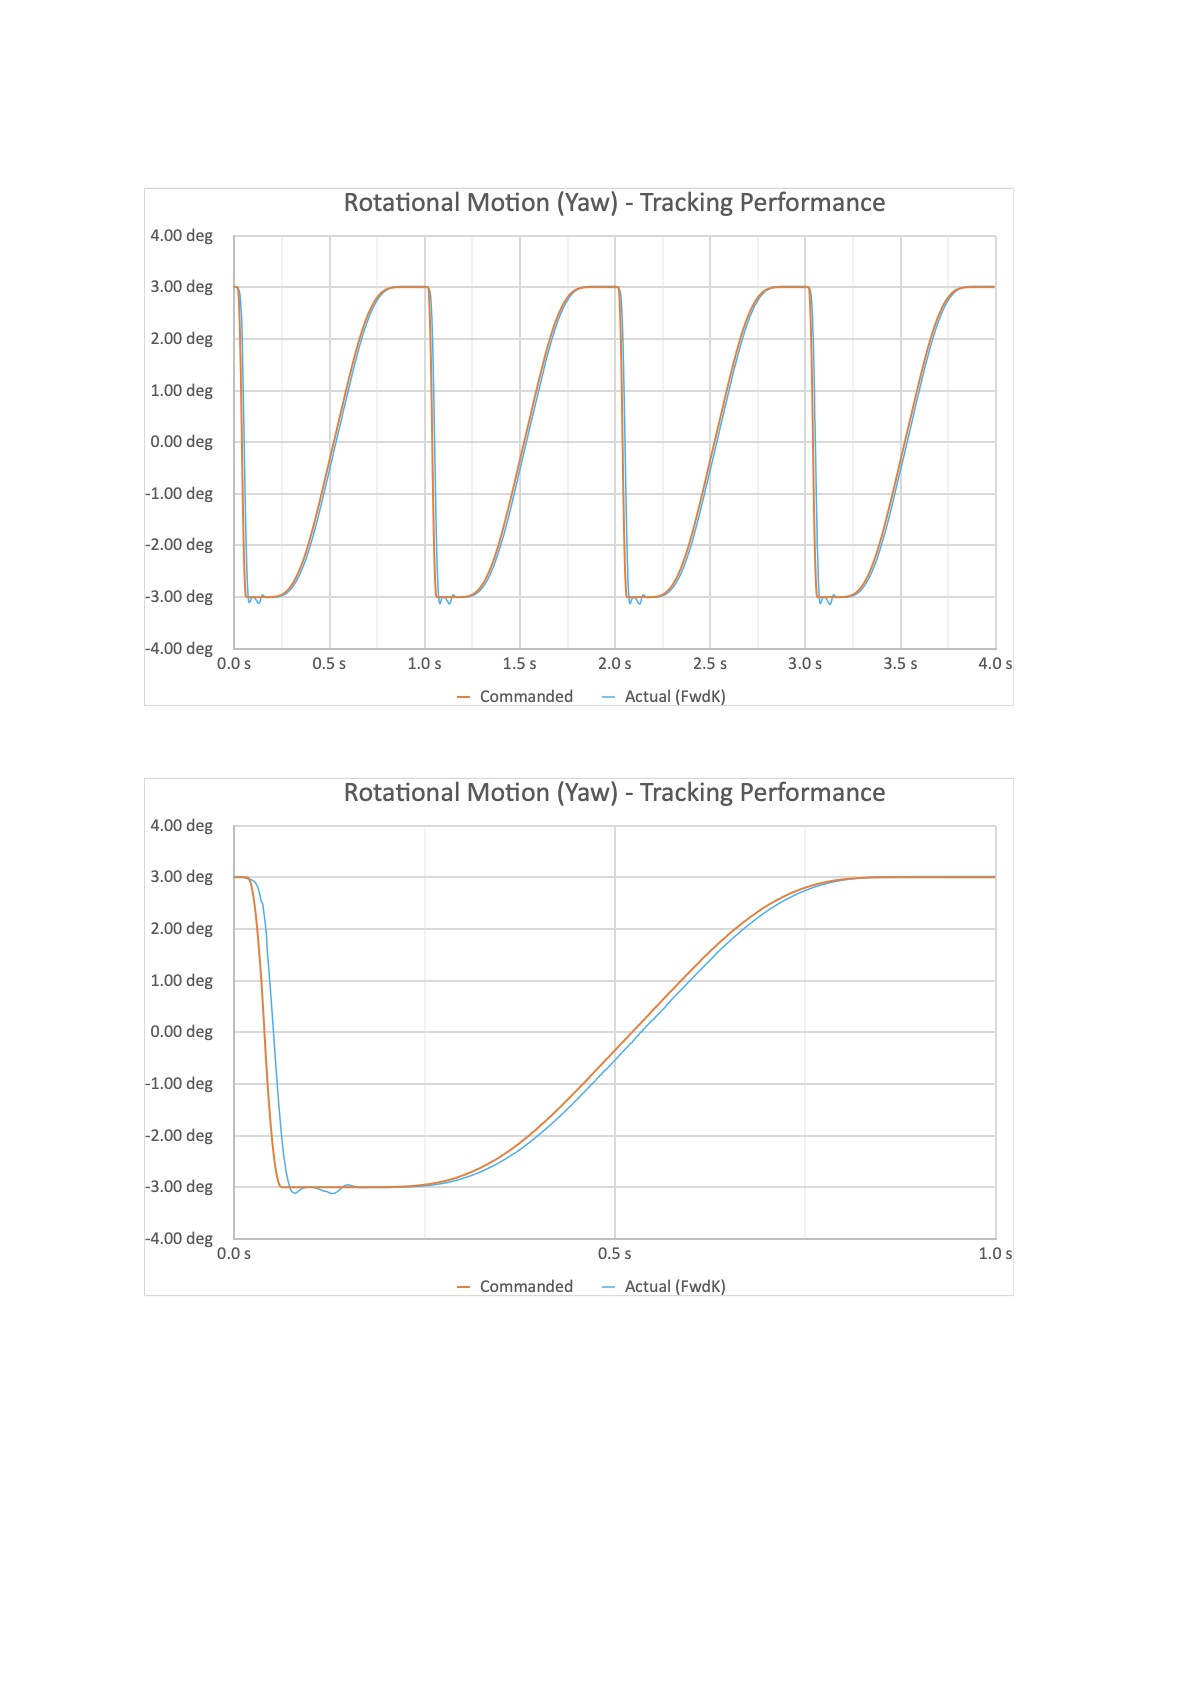
Live performance data shows exceptional tracking accuracy between commanded and actual positions. The system maintains microsecond precision while executing complex ballistic trajectories at multi-g accelerations.
Elegant Simplicity
Despite the complex underlying physics, the result is beautifully simple: a ball moving in perfect 1-second intervals around a clock face, defying gravity with each precise movement.
Build Details
Required Components
- ARK PDK 6-DoF Direct Drive Parallel Robot
- Teensy 4.1 Development Board with Ethernet
- 40.00mm diameter ball (squash ball)
- 690mm diameter × 15mm thick circular base (marine plywood)
- 10× Clock Face Segments (3D printed)
- Custom motion control software
Performance Data
The included graphs demonstrate:
- Precise acceleration profiles during catch trajectory
- Smooth snap-controlled return motion
- Real-time tracking performance showing commanded vs actual positions
Key Achievements
- Minimal-impact ball catching through calculated velocity matching
- Sub-millisecond position feedback and control
- Seamless integration of controlled motion phases
 Keith Elliott
 Anh Vu
 Piotr Sokólski