 Arya Patel
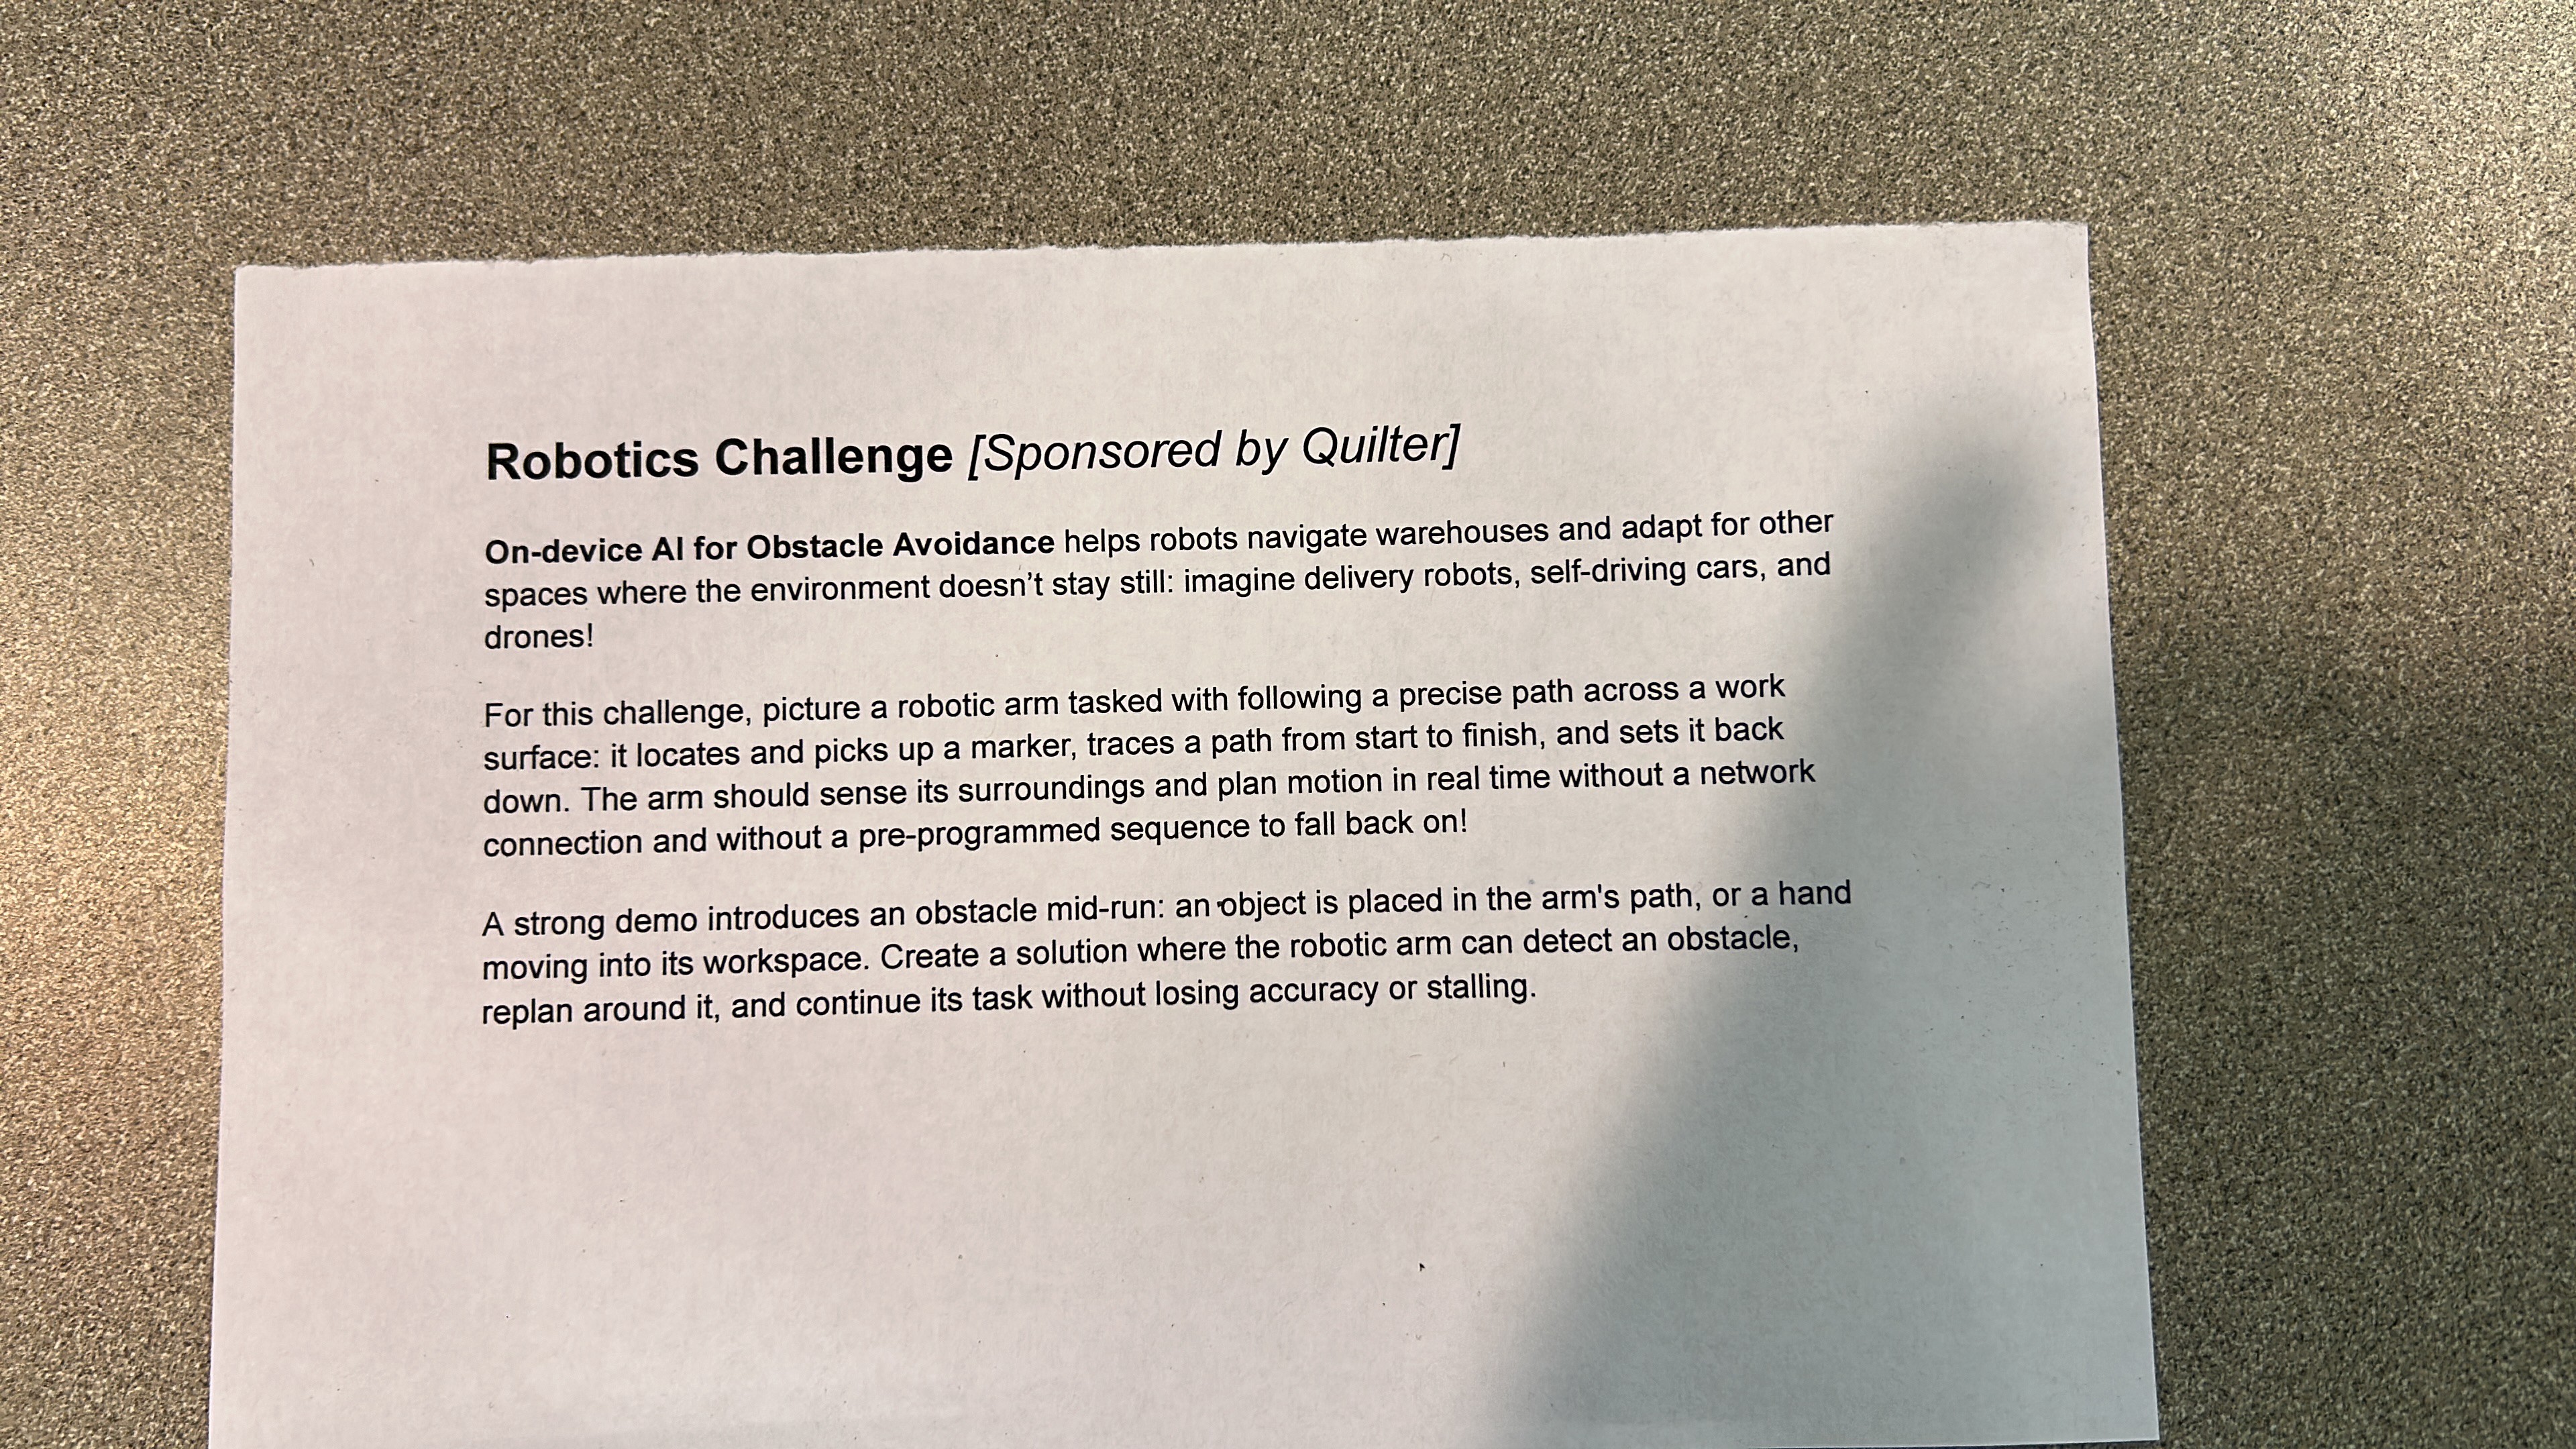
The challenge was handed out (first attached image) Tuesday (09/22/2026) morning 11:05 am. A robotic arm has to find and pick up a marker, trace a path from start to finish, and put the marker back down. It must plan its motion in real time with no network connection and no pre-programmed sequence. The strongest demos add an obstacle or a hand mid-run, and the arm has to detect it, replan around it, and keep going without losing accuracy.
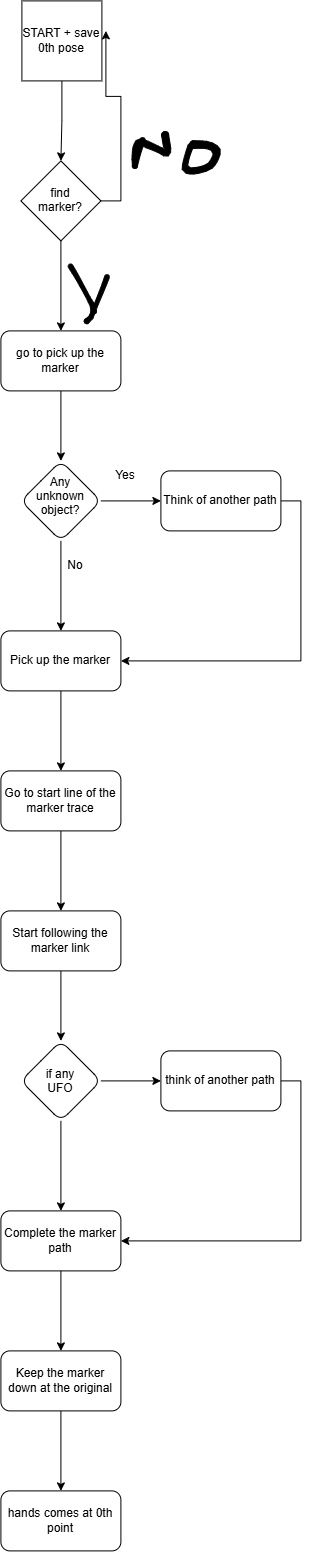
Before touching hardware, we sketched the task as a flowchart (second attachment): find marker, pick it up, go to the path start, follow the path, put the marker back, return home. Our first key design decision came from that sketch. Our first draft had separate "find another path" boxes for the approach and for tracing. We merged them into one shared routine called Guarded Move. It moves in small steps, checks the camera before each step, and detours if something is in the way. Every movement the arm makes uses this one loop.
Our first key decision came while drawing it. The first sketch had two separate "think of another path" boxes, one for the approach and one for tracing. We merged them into a single shared routine called Guarded Move. It moves in small steps, checks the camera before every step, and detours if something is in the way. Every movement of the arm uses this one loop, so obstacle handling works the same way in every phase of the task.
Discussions
Become a Hackaday.io Member
Create an account to leave a comment. Already have an account? Log In.