Close
0%
0%

CS12

CS12

Similar projects worth following
CS12

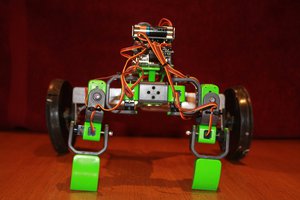
This project is a self-balancing robot.

Our goal is to build a 2-wheel robot that uses an IMU (gyro + accelerometer) and a PID-style control loop to stay upright. The robot will accept wireless joystick commands to drive forward/back and turn, and can also recover from small pushes/tilts while still moving. 

If there is additional time, extra features include enabling smoother driving, swappable trays on top, 2 lb payloads, and brushless motors.
IMG_3014 (1).MOV

Working project! It is able to stand up without falling.

quicktime - 21.41 MB - 03/19/2026 at 04:40

Download

motor_test.ino

ino - 1.82 kB - 02/23/2026 at 19:52

Download

code_test.ino

ino - 6.43 kB - 02/23/2026 at 19:52

Download

mpu_tilt_code.ino

Initial code to measure pitch/output sensing for MPU tilts.

ino - 2.84 kB - 02/07/2026 at 02:27

Download

  • 1 × Raspberry Pi Pico (RP2040)
  • 1 × MPU-6050 IMU module (gyro + accel, I2C)
  • 1 × Dual DC motor driver board (TB6612FNG)
  • 1 × nRF24L01+ radio module (receiver)
  • 1 × 10–47 µF electrolytic capacitor (for nRF24 power)

View all 9 components

  • Week 9 Progress!

    ssubramanian03/16/2026 at 23:09 0 comments

    - We have the motors working to resist/counteract changes in the Arduino tilt!

    - The robot is able to stay upright.

    - Although we weren't able to fulfill all of our goals for this project, we are very proud to share this working prototype. Future revision is something we are still interested in!

  • Week 6 Updates

    ssubramanian02/21/2026 at 01:31 0 comments

    WEEK 6 UPDATES:

    • Chassis assembly
    • Mounted everything, added radiomodule
    • Wrote new code
    • Current challenges: need to reprint chassis because it is currently held together by tape
    • New revised CAD design
      • Added slots for wires
      • Widened it because the battery is too big for chassis
      • Less empty space
      • Added slot for potentiometer
      • Make it so screws can fit with bigger tolerances
      • Slots instead of prongs, easier and more stable

  • Project Timeline

    ssubramanian02/07/2026 at 02:25 0 comments

    Current timeline:

    • 1/26: CAD layout (initial)
    • 2/2: Robot chassis assembled, motor test code committed
    • 2/9: IMU readout
    • 2/16: PD control code committed
    • 2/23: Tuning log + design review
    • 3/2: Verified failsafe behavior checklist + addition of nice-to-have features
    • 3/9: Final project demo

View all 3 project logs

Enjoy this project?

Share

Discussions

Similar Projects

Does this project spark your interest?

Become a member to follow this project and never miss any updates