Here is the code: https://github.com/wagnerc4/flight_controller
A stabilization system for drones using a pyboard, a MPU6050 and a RC receiver
To make the experience fit your profile, pick a username and tell us what interests you.
We found and based on your interests.
Here is the code: https://github.com/wagnerc4/flight_controller
Here the github repository:
The actual code for the pyboard are divided in 5 scripts:
rc.py -> read pwm from receiver
esc.py -> send pwm to speeds
mpu.py -> read accelerometer and gyroscope
pid.py -> stabilize the multicopter
main.py -> joins all scripts
And 1 script for the simulator on the laptop:
MPUTeapot.py
Now I'm working with the telemetry
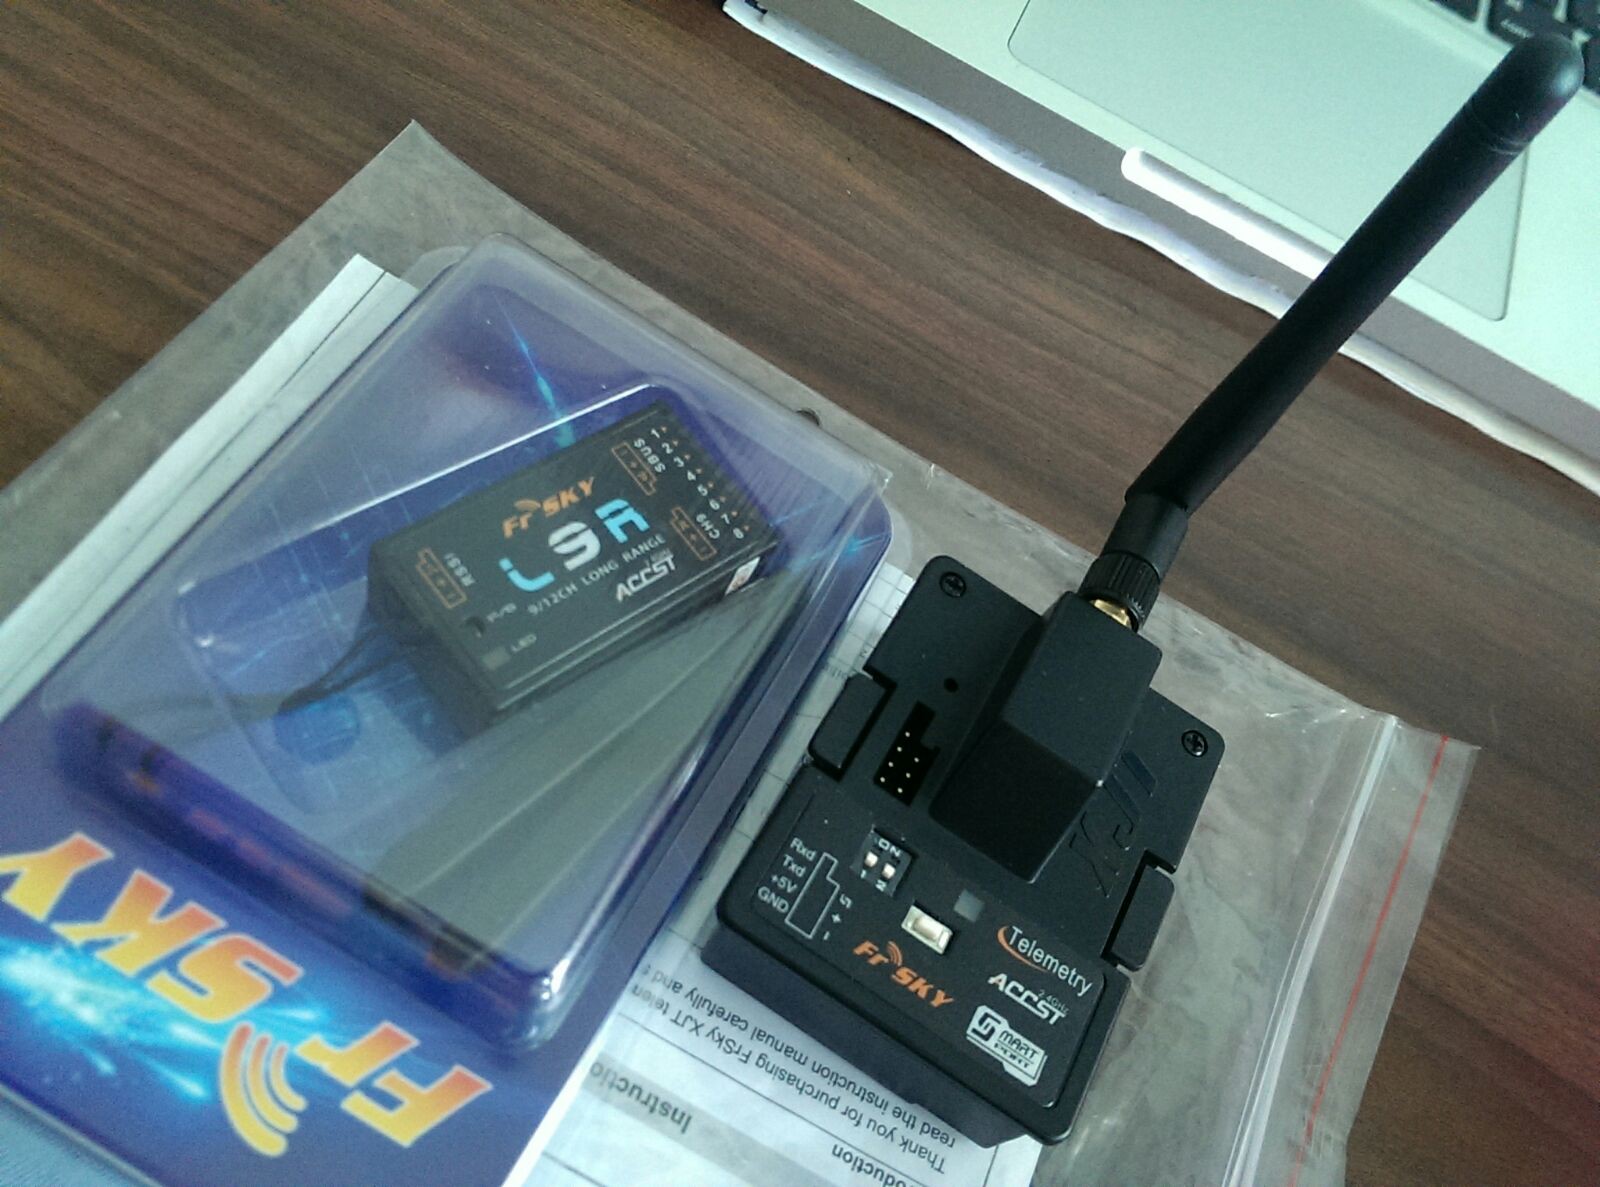
My FrSky transmiter y receiver has arrived!!!

Create an account to leave a comment. Already have an account? Log In.
The pyboard build-in accelerometer only have accelerometer.... The mpu6050 have gyroscope and accelerometer. In the main.py are commented the code for use the build-in accelerometer:
#accel = pyb.Accel()
imu = MPU6050()
.....
#x, y, z = accel.filtered_xyz()
x, y, z = imu.get_xyz()
......
You only have to switch this commented lines.
The problem with the built-in accelerometer is that when you shake, it throw wrong data... I have checked the accelerometer documentation and it can determine shake movements, but this feature seems not implemented in the micropython pyboard.
http://micropython.org/resources/datasheets/MMA7660FC.pdf
The mpu6050 doesn't have problems with shake movements....
But wait, doesn't pyboard have a build-in accelerometer already?
Become a member to follow this project and never miss any updates
By using our website and services, you expressly agree to the placement of our performance, functionality, and advertising cookies. Learn More
Finally found this